Drive.ai Navigates Rain and Broken Signal With Zero Disengagements
drive.ai
The autonomous vehicle platform traverses heavy downpours, oncoming glare, and an unexpected traffic cut-in without requiring safety driver intervention.
AI-assisted summary of drive.ai Rainy Night Autonomous Drive — original source. Check the original for full context.
Source published:
Key ideas
- Drive.ai demonstrated a fully autonomous drive through Mountain View, California, navigating severe weather and low-light conditions with zero safety driver interventions. (0:00)
- The autonomous platform successfully managed dynamic edge cases, including an abrupt, potentially illegal vehicle cut-in at a congested four-way stop. (1:00)
- The perception system demonstrated infrastructure resilience by safely treating an intersection with a malfunctioning, broken red traffic light as a controlled stop. (1:50)
- The vehicle maintained lane discipline and obstacle tracking despite intense optical challenges from oncoming headlight glare and mirror-like reflections on wet asphalt. (2:35)
Detailed notes
## Background Published on YouTube by autonomous vehicle company drive.ai on February 14, 2017, this demonstration highlights a fully autonomous drive conducted on a rainy night through Mountain View, California. According to the description, the vehicle required zero human interventions despite severe environmental challenges, including heavy downpour, glare on narrow roads, an abrupt vehicle cut-in at a four-way stop, a broken red traffic light, and confusing optical reflections off wet pavement.
## TL;DR The video showcases Drive.ai's self-driving vehicle navigating public streets in Mountain View under severe nighttime rain without a single driver takeover. Confronted with poor visibility, narrow streets bordered by parked cars, and intense head-on headlight glare, the autonomous stack maintains stable positioning and trajectory. The system successfully overcomes unpredictable edge cases, yielding to an oncoming vehicle that cuts across its path at a four-way stop and cautiously proceeding through an intersection featuring a broken red signal. The demonstration concludes along rain-slicked multi-lane roads, tracking lanes and surrounding traffic despite intense ground reflections.
## Atmosphere & style Accompanied by the buoyant electronic track 'Adventures' by A Himitsu, the presentation pairs a casual, upbeat soundtrack with the tense, moody reality of driving through a stormy night. The visual perspective through the rain-streaked windshield—pierced by bright oncoming glare and distorted reflections on wet asphalt—evokes an atmospheric, almost cinematic urban feel. Watching the vehicle smoothly glide past unexpected hazards like rogue cut-ins and dark traffic lights without any driver panic or sudden jerks produces a steady sense of quiet technical confidence.
## Bulletin - [00:00](https://www.youtube.com/watch?v=GMvgtPN2IBU&t=0s) Drive.ai demonstrated a fully autonomous drive through Mountain View, California, navigating severe weather and low-light conditions with zero safety driver interventions. - [01:00](https://www.youtube.com/watch?v=GMvgtPN2IBU&t=60s) The autonomous platform successfully managed dynamic edge cases, including an abrupt, potentially illegal vehicle cut-in at a congested four-way stop. - [01:50](https://www.youtube.com/watch?v=GMvgtPN2IBU&t=110s) The perception system demonstrated infrastructure resilience by safely treating an intersection with a malfunctioning, broken red traffic light as a controlled stop. - [02:35](https://www.youtube.com/watch?v=GMvgtPN2IBU&t=155s) The vehicle maintained lane discipline and obstacle tracking despite intense optical challenges from oncoming headlight glare and mirror-like reflections on wet asphalt.
## Key takeaways - [00:00](https://www.youtube.com/watch?v=GMvgtPN2IBU&t=0s) Drive.ai executed a complete autonomous test drive in Mountain View without any human intervention or disengagements. - [00:10](https://www.youtube.com/watch?v=GMvgtPN2IBU&t=10s) An intensifying heavy downpour began early in the drive, testing the system's tracking abilities under severely degraded optical visibility. - [00:30](https://www.youtube.com/watch?v=GMvgtPN2IBU&t=30s) The autonomous car successfully negotiated narrow residential corridors densely lined with parked vehicles on both sides. - [00:30](https://www.youtube.com/watch?v=GMvgtPN2IBU&t=30s) Direct optical glare from oncoming vehicle headlights reflected across the windshield and sensors without destabilizing path planning. - [01:00](https://www.youtube.com/watch?v=GMvgtPN2IBU&t=60s) The perception stack effectively negotiated a busy four-way stop with dynamic cross-traffic. - [01:00](https://www.youtube.com/watch?v=GMvgtPN2IBU&t=60s) When another vehicle unexpectedly cut directly in front of the car at an intersection, the system yielded appropriately to avoid a collision. - [01:50](https://www.youtube.com/watch?v=GMvgtPN2IBU&t=110s) The system encountered and correctly identified a malfunctioning traffic light displaying a broken red signal. - [01:50](https://www.youtube.com/watch?v=GMvgtPN2IBU&t=110s) Operating without standard signal cycles, the autonomous vehicle treated the failed intersection with caution, stopping and checking cross-traffic before proceeding. - [02:35](https://www.youtube.com/watch?v=GMvgtPN2IBU&t=155s) Standing water and puddles on multi-lane thoroughfares produced severe light scattering and mirror reflections from streetlights and neon signs. - [02:35](https://www.youtube.com/watch?v=GMvgtPN2IBU&t=155s) The perception stack reliably distinguished genuine lane boundaries and tracked leading vehicle headway despite confusing wet-ground optical artifacts. - [00:00](https://www.youtube.com/watch?v=GMvgtPN2IBU&t=0s) The test demonstrated self-driving capability across compounded adverse edge cases: night driving, heavy rain, infrastructure failure, and unpredictable human driving.
## Detailed walkthrough ### [00:00](https://www.youtube.com/watch?v=GMvgtPN2IBU&t=0s) Autonomous Driving in Heavy Downpour and Street Glare
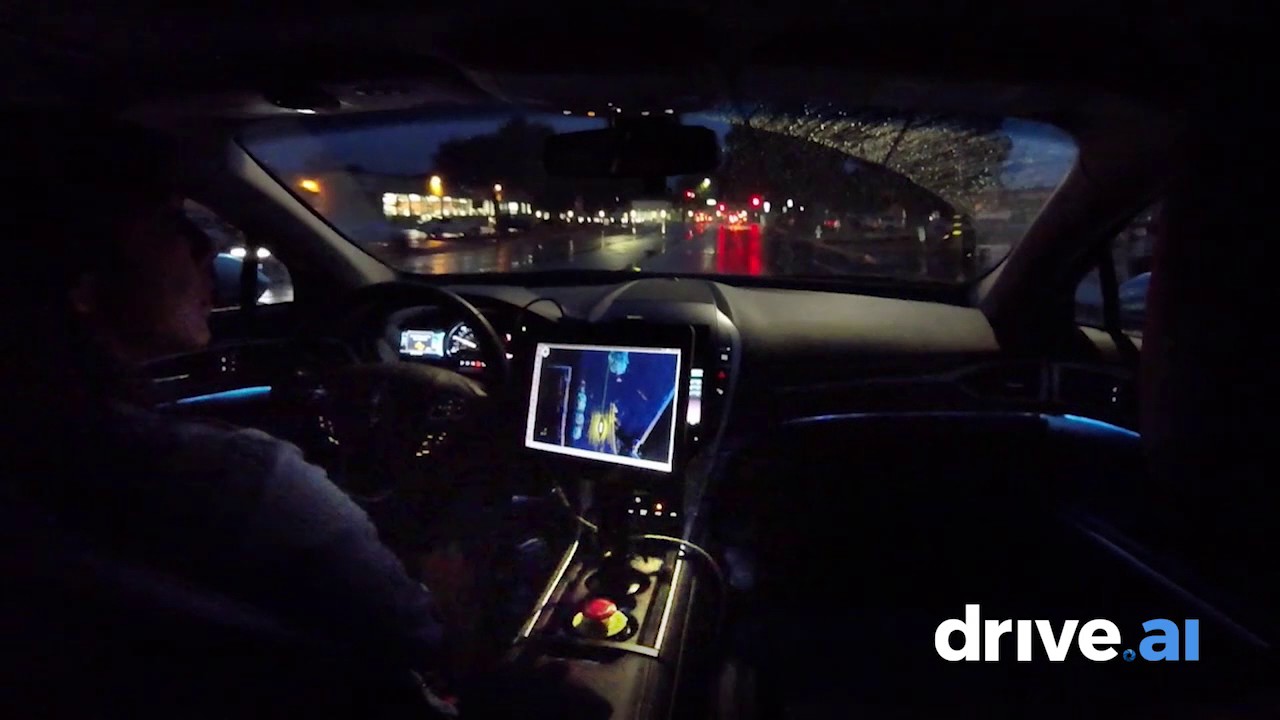
Drive.ai demonstrates a fully autonomous evening drive through the streets of Mountain View, California, conducted under severe weather and low-light conditions with zero human intervention throughout the run. The demonstration begins against the soundtrack of “Adventures” by A Himitsu, capturing the vehicle navigating through an intensifying heavy downpour. Large raindrops batter the windshield while the autonomous system processes the surrounding visual field, maintaining lane discipline and trajectory despite degraded visibility and streetlights blurring across the glass.
The vehicle soon transitions onto narrower residential and urban roadways crowded with vehicles parked tightly along both curbs. In this segment, the system faces direct optical glare from oncoming vehicle headlights reflecting across the windshield and camera lenses. The self-driving platform safely tracks the available drivable corridor, pacing its movement past obstacles and incoming headlights without disengaging or requiring driver override.
- Location: Public roadways in Mountain View, California. - Operating conditions: Nighttime conditions accompanied by heavy rainfall and reduced visibility. - Navigation challenge: Narrow urban corridor bordered by parked cars while facing intense head-on headlight glare.
[01:00](https://www.youtube.com/watch?v=GMvgtPN2IBU&t=60s) Navigating 4-Way Stops and Traffic Signal Outages
The vehicle approaches a bustling four-way stop intersection where traffic conditions become noticeably dynamic and unpredictable. While negotiating right-of-way, another vehicle abruptly and potentially illegally cuts directly in front of the Drive.ai test car. The perception and planning stack detects the crossing vehicle, yielding appropriately to avoid a collision before proceeding through the intersection once the path is clear.
Shortly after clearing the four-way stop, the vehicle encounters a malfunctioning traffic signal displaying a broken red light at a subsequent intersection. Operating without standard operational light cycles, the car treats the degraded intersection cautiously, identifying cross-traffic flow, coming to a controlled stop, and executing a safe passage through the crossing once clear.
```mermaid flowchart TD accTitle: Autonomous Vehicle Hazard Handling Flow accDescr: Flowchart showing how Drive.ai navigates unexpected traffic hazards including cut-ins and malfunctioning signals.
subgraph FourWayStop["4-Way Stop Navigation"] A["Approach 4-Way Stop"] --> B["Detect Crossing Cut-in Vehicle"] B --> C["Yield and Wait for Clearance"] end
subgraph SignalFailure["Traffic Signal Outage"] D["Approach Malfunctioning Intersection"] --> E["Identify Broken Red Light"] E --> F["Treat as Controlled Stop"] F --> G["Proceed Safely Through Intersection"] end
C --> D ```
- Intersection management: Safely handles an unexpected cut-in from a conflicting vehicle at a busy 4-way stop. - Infrastructure resilience: Effectively interprets and navigates an intersection experiencing a broken red traffic signal without human assistance.
[02:35](https://www.youtube.com/watch?v=GMvgtPN2IBU&t=155s) Handling Wet Road Surface Reflections at Night
In the final stretch of the demonstration, the vehicle traverses broader multi-lane thoroughfares where puddles and standing water produce confusing optical mirror effects. The wet ground reflects overhead street lamps, neon signs, and vehicular tail lamps, creating distorted visual cues that frequently challenge computer vision and LIDAR perception pipelines. The autonomous system continues to isolate lane boundaries and track vehicle headway amidst the ground reflections.
The video concludes with the autonomous vehicle safely completing its route through Mountain View's rain-slicked city streets, completing the entire journey from heavy downpour to complex nighttime reflections without a single intervention from the safety driver.
- Environmental difficulty: Highly reflective wet asphalt scattering light from overhead lamps and vehicle brake lights. - System outcome: Complete end-to-end autonomous navigation without manual takeovers or system disengagements.
## Mentioned Drive.ai, Mountain View, California, A Himitsu, Adventures (song), Audio Library
## Video description A fully autonomous drive on a rainy night on the streets of Mountain View, CA. Learn more or join our team at https://www.drive.ai/
Some highlights about the video: • Fully autonomous driving during the entire video. No human intervention. • Starting from 0:10 heavy downpour. • 0:30 Narrow street with parked cars and glare from oncoming traffic. • 1:00 Busy 4-way stop sign and a car (possibly illegally) cutting in front of the Drive.ai car. • 1:50 Broken red light at intersection • 2:35 Night driving with confusing reflections from the wet ground.
Adventures by A Himitsu https://soundcloud.com/a-himitsu Creative Commons — Attribution 3.0 Unported— CC BY 3.0 http://creativecommons.org/licenses/b... Music provided by Audio Library https://youtu.be/MkNeIUgNPQ8
[Source](https://www.youtube.com/watch?v=GMvgtPN2IBU)