TU Vienna Engineers Test Pendulum Cart System Amid Strained Lab Run
Tobias Glück
Dynamic balance maneuvers using constrained feedforward and optimal feedback control provoke audible stress and apologies during live cart runs.
AI-assisted summary of Double Pendulum on a Cart — original source. Check the original for full context.
Source published:
Key ideas
- The experiment demonstrates dynamic control of a double pendulum on a cart developed at TU Vienna ACIN CDS by Andreas Eder and Tobias Glück.
- The control scheme implements a two-degrees-of-freedom design combining constrained feedforward control with optimal feedback control.
- The demonstration protocol evaluates 12 point-to-point control maneuvers and 4 side-stepping operations.
- The accompanying live audio captures an atmosphere of high tension, marked by vocal encouragement, nervous laughter, and gasps during the run. (0:00)
Detailed notes
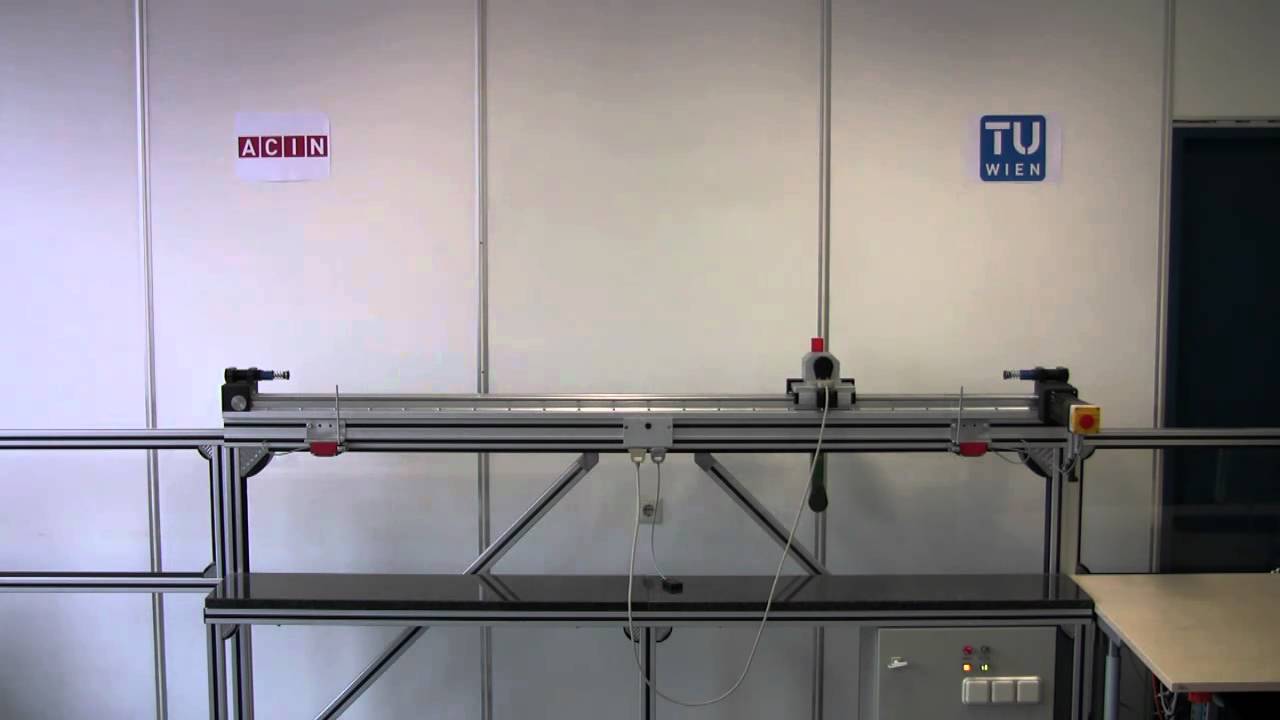
## Background Published on YouTube by Tobias Glück on March 29, 2011, this video showcases a double pendulum on a cart demonstration developed by Andreas Eder and Tobias Glück at TU Vienna ACIN CDS. According to the description, the project features a two-degrees-of-freedom design using constrained feedforward and optimal feedback control to achieve 12 point-to-point controls and 4 side-stepping maneuvers.
## TL;DR The recording documents the tense live audio during a dynamic double pendulum on a cart run. The session opens with urgent encouragement of 'Come on! Come on!' as the apparatus begins its movement, promptly met with an initial 'Thank you.' Throughout the sequence, the room experiences fluctuating waves of stress marked by audible gasps, scoffing, strained breathing, and uneasy laughter amidst ambient pauses. Toward the end of the demonstration, a heavy pause and strained breath precede a brief 'I'm sorry' before the run concludes with several repeated acknowledgments of 'Thank you.'
## Atmosphere & style The atmosphere is intensely fraught and emotionally charged, swinging between sharp suspense and tentative relief. Listening to the audio feels intimate and nerve-wracking, as heavy silences are broken by strained breathing, distress, audible gasps, and nervous scoffs. The emotional arc moves from desperate initial urging into a high-stakes, breathless watch, finally resolving in an apologetic yet polite wrap-up.
## Bulletin - The experiment demonstrates dynamic control of a double pendulum on a cart developed at TU Vienna ACIN CDS by Andreas Eder and Tobias Glück. - The control scheme implements a two-degrees-of-freedom design combining constrained feedforward control with optimal feedback control. - The demonstration protocol evaluates 12 point-to-point control maneuvers and 4 side-stepping operations. - [00:00](https://www.youtube.com/watch?v=B6vr1x6KDaY&t=0s) The accompanying live audio captures an atmosphere of high tension, marked by vocal encouragement, nervous laughter, and gasps during the run.
## Key takeaways - The setup showcases a double pendulum on a cart system developed under TU Vienna's ACIN CDS research group. - A two-degrees-of-freedom control architecture is utilized, coupling constrained feedforward with optimal feedback control. - The experimental run features 12 point-to-point control executions and 4 side-stepping maneuvers. - The technical work was carried out by researchers Andreas Eder and Tobias Glück. - [00:00](https://www.youtube.com/watch?v=B6vr1x6KDaY&t=0s) The live recording opens with urgent vocal encouragement ('Come on! Come on!') as the cart and pendulum engage in motion. - [00:00](https://www.youtube.com/watch?v=B6vr1x6KDaY&t=0s) The room's reaction reflects fluctuating emotional states, alternating between sharp tension, silence, and nervous relief. - [00:00](https://www.youtube.com/watch?v=B6vr1x6KDaY&t=0s) Audible reactions include gasps, scoffing, and strained breathing throughout the difficult control sequence. - [00:00](https://www.youtube.com/watch?v=B6vr1x6KDaY&t=0s) Uneasy laughter and audible distress underscore the high stakes and precision demands of the physical demonstration. - [00:00](https://www.youtube.com/watch?v=B6vr1x6KDaY&t=0s) The phrase 'Thank you' is stated repeatedly across multiple segments of the run. - [00:00](https://www.youtube.com/watch?v=B6vr1x6KDaY&t=0s) A brief apology ('I'm sorry') is spoken toward the conclusion following a heavy pause and tense breathing. - [00:00](https://www.youtube.com/watch?v=B6vr1x6KDaY&t=0s) The session concludes with successive remarks of 'Thank you' as the demonstration completes.
## Detailed walkthrough ### [00:00](https://www.youtube.com/watch?v=B6vr1x6KDaY&t=0s) Demonstration Audio and Live Reactions
The audio recording captures a tense and emotional atmosphere during the double pendulum on a cart demonstration. The track opens with an urgent, encouraging call of “Come on! Come on!” as the dynamic experiment is set into motion, immediately followed by an initial acknowledgment of “Thank you.” The room's mood fluctuates between sharp tension and nervous relief, marked by audible gasps, scoffing, strained breathing, and background ambient sounds punctuated by silence.
As the sequence progresses, the heightened emotion continues with a mixture of uneasy laughter, audible distress, and further gasps. Through the strain and tension, repeated acknowledgments of “Thank you” are offered to those present. Toward the conclusion of the recording, following a heavy pause and strained breathing, a brief apology is spoken: “I'm sorry.” This is followed by a succession of closing remarks reiterating “Thank you” as the run wraps up.
- Spoken dialogue includes the direct urging “Come on! Come on!” alongside the apology “I'm sorry.” - The phrase “Thank you.” is repeated multiple times throughout the recording amidst ambient pauses, gasps, and nervous laughter.
## Mentioned Andreas Eder, Tobias Glück, TU Vienna (ACIN CDS)
## Video description Double Pendulum on a Cart 12 x point-to-point control and 4 x side-stepping
Two-degrees-of-freedom design: Constrained feedforward & optimal feedback control
TU Vienna ACIN CDS http://www.acin.tuwien.ac.at/
Done by Andreas Eder and Tobias Glück
http://users.acin.tuwien.ac.at/tglueck/
[Source](https://www.youtube.com/watch?v=B6vr1x6KDaY)