Tesla Autopilot 17.7.2 Drifts Into Oncoming Lanes During Road Tests
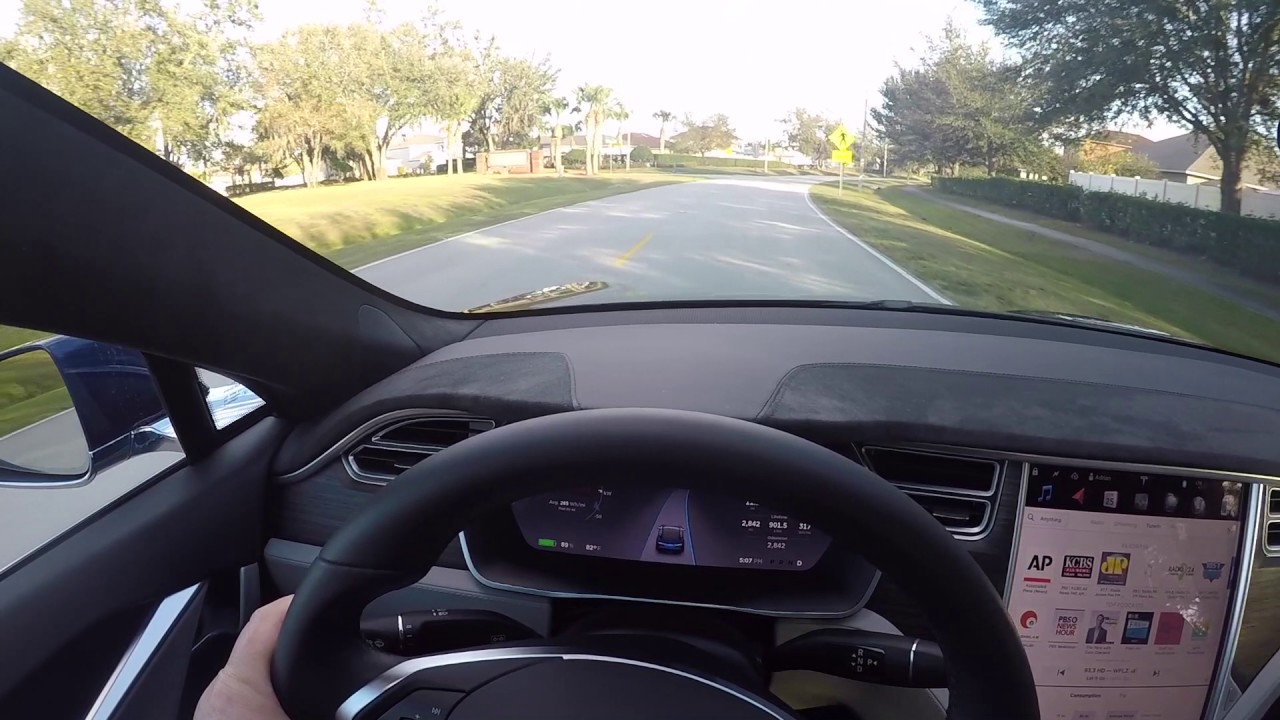
Tesla Autopilot 17.7.2 Fails — DeRage

DeRage

Testing shows Tesla's second-generation Autopilot firmware remains in its infancy, repeatedly locking onto center dividers as lane paths and drifting toward curbs under faded markings and solar glare.

AI-assisted summary of Tesla Autopilot 17.7.2 Fails — original source. Check the original for full context.

Source published:

Key ideas

  • Tesla Model S Autopilot firmware 17.7.2 struggled severely with lane-keeping on rural and reserve roads, failing to negotiate curved concrete islands even at minimum speeds of 18–19 mph. (0:01)
  • On marked two-lane side streets at 30 mph, the system repeatedly mistook the painted double yellow center divider for the lane track, straddling the center of the road into opposing traffic. (17:42)
  • The host and viewers compared the raw, erratic performance of second-generation Autopilot (AP2) on 17.7.2 to the infancy of the original AP1 launch, expecting rapid over-the-air improvements. (21:45)
  • Autopilot was capped below 35 mph on local roads, disengaging immediately at 37 mph, and failed to recognize dead-end signs or stop for red lights automatically. (17:42)

Detailed notes

## Background Published on YouTube by the channel DeRage on February 26, 2017, this video documents a real-world test of the Tesla Model S Autopilot firmware version 17.7.2. According to the video description, the creator aimed to evaluate the capabilities and limitations of the system, capturing several expected and unexpected failures during the drive.

## TL;DR The video features a hands-on test of Tesla's Autopilot firmware version 17.7.2 across various challenging environments, including a wildlife reserve, narrow side streets, and unmarked residential roads. Throughout the drive, the system repeatedly fails to maintain lane discipline, drifting over curbs at low speeds, straddling double yellow center lines at 30 mph, and ignoring a dead-end sign. While the host notes the system performs adequately on standard, busy roads, he highlights its severe struggles with faded markings, direct sunlight glare, and non-standard road widths. Ultimately, he draws comparisons to the early, primitive days of AP1 and outlines plans for future tests, including documenting the vehicle's hands-off safety lockout protocol.

## Atmosphere & style The video has the candid, unpolished feel of an authentic DIY road test, driven by the host's calm yet skeptical commentary. There is a palpable tension when the vehicle drifts toward curbs or oncoming traffic, contrasted by the host's lighthearted banter, such as jokingly pitching a tax-free 'Tesla Church' near local rural chapels. Watching the footage feels like sitting in the passenger seat of an early-adopter experiment, capturing both the nervous anticipation of system failures and a genuine curiosity about the rapid evolution of autonomous driving technology.

## Bulletin - [00:01](https://www.youtube.com/watch?v=UZ1XLqc5IUg&t=1s) Tesla Model S Autopilot firmware 17.7.2 struggled severely with lane-keeping on rural and reserve roads, failing to negotiate curved concrete islands even at minimum speeds of 18–19 mph. - [17:42](https://www.youtube.com/watch?v=UZ1XLqc5IUg&t=1062s) On marked two-lane side streets at 30 mph, the system repeatedly mistook the painted double yellow center divider for the lane track, straddling the center of the road into opposing traffic. - [21:45](https://www.youtube.com/watch?v=UZ1XLqc5IUg&t=1305s) The host and viewers compared the raw, erratic performance of second-generation Autopilot (AP2) on 17.7.2 to the infancy of the original AP1 launch, expecting rapid over-the-air improvements. - [17:42](https://www.youtube.com/watch?v=UZ1XLqc5IUg&t=1062s) Autopilot was capped below 35 mph on local roads, disengaging immediately at 37 mph, and failed to recognize dead-end signs or stop for red lights automatically.

## Key takeaways - [00:01](https://www.youtube.com/watch?v=UZ1XLqc5IUg&t=1s) Direct solar glare combined with faded white lines severely hindered camera vision processing during initial testing. - [00:01](https://www.youtube.com/watch?v=UZ1XLqc5IUg&t=1s) Autopilot failed repeatedly to negotiate a curved concrete traffic island at 18–19 mph, drifting toward the grass and requiring manual intervention. - [00:01](https://www.youtube.com/watch?v=UZ1XLqc5IUg&t=1s) The digital instrument cluster display showed inaccurate vehicle positioning relative to actual painted road markings. - [00:01](https://www.youtube.com/watch?v=UZ1XLqc5IUg&t=1s) The operational speed ceiling on local side roads locked out Autopilot above 35 mph, disengaging if pushed to 37 mph. - [00:01](https://www.youtube.com/watch?v=UZ1XLqc5IUg&t=1s) The system successfully detected forward traffic and managed slowing down, but failed to recognize or stop for red traffic lights. - [17:42](https://www.youtube.com/watch?v=UZ1XLqc5IUg&t=1062s) Autopilot executed an unprovoked hard phantom-braking event on an open roadway without forward obstacles. - [17:42](https://www.youtube.com/watch?v=UZ1XLqc5IUg&t=1062s) On a marked 30 mph side road, Autopilot locked onto the double yellow center line as the middle of its path rather than staying centered inside the travel lane. - [19:18](https://www.youtube.com/watch?v=UZ1XLqc5IUg&t=1158s) The vehicle completely crossed into the opposing travel lane while approaching a dead end, failing to register dead-end or no-trespassing signage. - [21:45](https://www.youtube.com/watch?v=UZ1XLqc5IUg&t=1305s) Narrower road widths and subtle curbs caused the system to drift erratically across center markings even when painted lines were crisp. - [21:45](https://www.youtube.com/watch?v=UZ1XLqc5IUg&t=1305s) Viewers and the driver drew parallels between early AP2 releases like 17.7.2 and the rough initial customer rollout of Mobileye-based AP1. - [23:48](https://www.youtube.com/watch?v=UZ1XLqc5IUg&t=1428s) On completely unmarked roadways, Autopilot attempted tracking but required manual disengagement when oncoming traffic approached. - [23:48](https://www.youtube.com/watch?v=UZ1XLqc5IUg&t=1428s) Lane tracking immediately recovered once standard painted lane markings reappeared past an unmarked intersection. - [23:48](https://www.youtube.com/watch?v=UZ1XLqc5IUg&t=1428s) Future testing plans included wearing a head strap camera mount and intentionally testing the escalation sequence of hands-off steering wheel alerts.

## Detailed walkthrough ### [00:01](https://www.youtube.com/watch?v=UZ1XLqc5IUg&t=1s) Autopilot Struggles in a Wildlife Reserve

DeRage begins testing the latest Tesla Model S Autopilot firmware (version 17.7.2). After being dissatisfied with his camera angle in a video shot the previous day, he adjusted his setup to give viewers a clearer vantage point of the road and dash. The test begins on an empty road inside a wildlife reserve with no traffic or bystanders around. Almost immediately, the system acts up when the lane markings end, failing to keep the car centered and drifting straight over the line. Driving directly against the glaring sun complicates vision processing further, making it difficult for the vehicle to detect faint, aged lane markings.

When the Tesla approaches a curved concrete traffic island, the system fails to negotiate the bend entirely, aiming straight off the road toward the grass. Because the test is taking place in an isolated nature preserve with only open grass at the roadside, the host intentionally lets the vehicle drift until intervention is necessary to prevent a collision with the curb. Even at minimal speeds of 18 to 19 mph, the car refuses to track the curve, forcing manual overrides. DeRage observes that while the system senses the curb, it relies heavily on clear white lines to guide its trajectory, which are faded here.

```mermaid flowchart TD accTitle: Autopilot Wildlife Reserve Curve Failure accDescr: Diagram illustrating the failure sequence of Tesla Autopilot navigating an island curve in the reserve. subgraph S1["Environmental Inputs"] A["Faded White Road Markings"] B["Direct Sunlight Glare"] C["Raised Concrete Curb / Island"] end subgraph S2["Autopilot Processing"] D["Computer Vision Misinterprets Road Edge"] E["Instrument Cluster Shows Incorrect Position"] end subgraph S3["Vehicle Reaction & Driver Action"] F["Drifts Toward Island Grass"] G["Driver Intervenes to Avoid Curb Impact"] end A --> D B --> D C --> D D --> E D --> F F --> G ```

- System firmware tested: Tesla Autopilot version 17.7.2. - Testing speed through the reserve curves: 18 to 19 mph (18 mph is the absolute lowest operational speed set by the driver). - Environmental challenge: Direct sunlight heading directly into the forward-facing camera system combined with faded lane markings.

> “So this road is in the middle of nowhere so and um it's probably going oh look at that act up already you did not know what to do once the lanes uh finish also we're going against the sun right now so we're doing this test good thing there's nobody around us and we're over the line already I don't know if you guys can see that um we found the middle of the right lane now there's this little island over here I don't think it'll be able to negotiate it and look at that it did not negotiate that at all um and obviously I just let that happen because are in the midd of nowhere it's just grass and no Wildlife we harmed we're in a Wildlife Reserve um and there is nobody else around and it can never make this uh turn back so it turns from the island is notices the curb but uh it basically does not find the white line I mean you know for this is a old white line you know kind of like Fad in and stuff but still it should be able to to negotiate this turn um I guess it's it relies a lot on the white line as you guys can see we're also going against the sun which doesn't help very much let's see I en a little late and we're going to D in the grass again unless I correct it and we're going like you know 19 M an hour uh the lowest the we can go is 18 which basically is no change whatsoever but you know I want to do this test I don't want to hit the curb U because you know that time it looked like it was actually going to hit the curve so on this road autopilot is not working very well um but you know it's kind of to be expected I suppose so let's see if it's going to do this one no I don't want them okay I think we're going to have to go and try in other the roads because this road is basically a disappointment and if you go fast and slow it doesn't doesn't seem to impact it all right yeah obviously I wouldn't try this in a regular road but um and I don't know if you guys can see the actual Dash the lines right you might be able to see the lines over here when we making the curve uh he thinks we're in the middle of the road when we're not he thinks we're like over the line when we're not so enable again and he not going to do it I guarantee it so that's the state the autopilot is on right now oh maybe almost so almost did that last one but if you if you notice the um on the screen over here you see that it thinks uh when I'm going the right way it thinks the line is further to the right and is not all right so oh takes a few seconds to recognize the lines after the curve so let's see this one they all the same I mean they all the same um measurement and things like that maybe you'll do this one yeah actually did this one but then we go right in the middle of the uh of the other line of the other Lane right so he actually did one guys uh but you did not help because s do in the left lane at least it's mud enough to know that's in the wrong place afterwards right um yeah but that is uh what is it 17. 7.2 something like that forw so I just want to do another video probably like drive out of here into another local road which no traffic and I took control there because there was a little uh um bump in the road and just for the heck of it let's up the speed on this one uh I don't go let's see 30 no yeah so uhoh they closed oh no I thought they closed the gate on me I was going to say no but they Clos the entrance I'll be stuck in the reservation the Wilderness reservation that would not be pretty at all all right so let's try on this road this road is fairly quiet as well it's a very local Road it's a very small road too so that is that might be a problem in itself um it's already going in the middle of the road but I'm going to let it go because I just want to see what it's going to do it's right in the middle does not see these Lanes at all and there's cars behind me now so not behind but they're going to turn behind me so I'm basically taking over so that did not work let's see yeah and if you look at the display I am not over the white line uh in the side but it thinks that I am so that's what's important the camera it's not very um accurate yet as far as like the you know knowing where the line is and whatnot cuz it thinks I'm over it right now and I'm not I'm close to it but not over the line but like I said it's a small not not small but like um not a very wide a narrow world that's the word I was looking for so we got to wait for this light might take a while yay imagine that you opened finally all right now let's see can we use it here yeah we can use it here but I don't trust here too much cuz it's actually a busy road one thing I noticed too that if I speed above 35 it doesn't disengage right away I think if if I go like 36 it still works oh no at 37 it disengages but I can actually go 36 without I did it before anyways all right so you know right now it's on autopilot there's some traffic over here so it should stop let's pray and it does um they fix the bug on the display but the cars don't turn blue yet they turn white and we're going against the Sun so it's working pretty good and here we go and now he wants me to hold the steering wheel so we'll do that so he keeps on driving happily car slowing down in front of us and slows down that's good yeah so there's some traffic so we actually get to use in a normal road and it works pretty good in a normal road so far everybody's passing me though so I got to go yeah because it's very slow 35 is not going to cut in this road at least for now for a long time people going to be seeing damn electric car so slow man them slow autopilots so there's this road uh that's not really a road it's like a community just going to go there but I mean it is a road but inside of a community I'll test for another few minutes so we can see how it works I want to try this I don't know what's going to happen but okay going to slow down here manually because the car is about to turn and the sensor prob wouldn't see him not yet not without an update okay green light even if it wasn't we could turn on red thanks Flor there it's pretty good so we go 35 cuz it is a 45 M hours uh miles an hour here but we can actually turn off over there and uh yeah we're going to take over we'll turn off in the uh side roads over here then we can test all we want and should be very uh quiet as well not as busy as this so I noticed that right now well yeah right now a pilot is not available so whenever you go above 35 it doesn't even show the option to be available okay we're going to turn here I think it's another Community but there should be some local roads for us yeah it is a community but don't matter we just need to be quiet and safe 35 35 mile lanes are a little bit faded so now it's good let's see is he going to turn am I yes it turned I don't know why but I don't trust the the single you know the broken down whatever it's called the lane the middle that's when it's yellow it tends to go over for some reason like right now it's trying to negotiate it trying to figure out but it's very much to the left and now oh take over there don't want to hit the sign and now it's not available because they're fading so one thing I noticed yesterday did much better I don't know if it was the weather I think it was it could have been the weather I don't remember if it was really sunny I thought it was really sunny but yesterday he worked a little bit better um recognizing um Lanes without actually having Lane on him today seems to be a little bit worse see but what are we going to do speed up a little bit so we can take this light cuz we don't want to be waiting half an hour again these lights can take a while all right so 35 again as long as there is nobody behind me I don't mind it and there's two lanes too so they can pass oh they want so since yesterday I must driven like maybe like 20 miles on autopilot if I were to guess maybe more just testing it and you know just seeing how he behaves and basically training the fleet no okay so people must drink I'm drunk sometimes cuz I mean drives okay but not a perfect driver by any means at all so I don't know what people think but hopefully not that I'm drunk call the cops I'm not even driving it red light is it going to stop at the red light no but why not man it should but it won't so okay but we stopped actually they should have turned here but they didn't awkward silence honestly I don't want people think I'm crazy nobody thinks that anymore everybody talks some speaker phones inside the car I remember when Bluetooth first came out you thought people were crazy talking you know to themselves inside the car that was a thing nobody used to talk you know when Bluetooth renew and stuff now once the lane closes then we can go still green to turn even though nobody's going to turn that's why you L musk need to work on make it like lights be smarter cuz they're not very smart right now yeah yeah went over the spill limit not spill limit but the uh autopilot limit yeah this road it's not very good for testing at all actually there is no roads in here they are very good for testing um I know this one's not but you know at least we got to use it a little bit that test was very telling at the uh Community well not Community uh the what”

[17:42](https://www.youtube.com/watch?v=UZ1XLqc5IUg&t=1062s) Line Detection Failure and Lane Straddling at 30 MPH

After driving past what he refers to as the reservation, the host experiences an abrupt and jarring reaction from the Tesla Model S. Without any apparent obstacle ahead, the vehicle applies a hard, unprompted brake. He dismisses the sudden deceleration as completely unnecessary and turns onto a side road, noting that he needs to head toward the gym area where his son is finishing up. Turning onto this stretch of asphalt, he prepares to evaluate how the newly released 17.7.2 Autopilot build manages standard roadway markings, which here consist of clear outer white shoulder lines and a painted double yellow line down the center.

Setting the vehicle’s cruise speed to 30 mph, the driver watches the instrument cluster and the steering wheel closely. Despite the markings being clearly visible to the human eye, the Autopilot system fails to distinguish the travel lane. Instead of centering the car between the right edge line and the center stripe, the car tracks directly over the center divider itself. The driver expresses disbelief as the vehicle locks onto the yellow divider line as if it were a target track, centering the car squarely down the middle of the entire road. Frustrated by the car's inability to recognize obvious visual boundaries, he exclaims, “I don't know why but it's like does not see those lines at all I don't know if you guys can see it I can certainly see the lines but the car autopilot does not see it look at that it goes right in the middle it takes us a line to follow the bdle it's like okay I should follow this line it's right you know keep it in Keep It Center keep in the middle but no.”

```mermaid flowchart TD accTitle: Autopilot Road Tracking Behavior accDescr: Sequence of road conditions tested on firmware 17.7.2 and the corresponding Autopilot failures and interventions.

subgraph MarkedRoad["Marked Two-Lane Road (30 MPH)"] A["Double Yellow Center Lines"] --> B["Autopilot misidentifies center stripe as lane center"] B --> C["Car straddles center line into opposing traffic"] end

subgraph ChurchRoad["Dead-End & Church Stretch"] D["Approaching Dead End"] --> E["Car fails to detect 'Dead End' / No Trespassing"] E --> F["Manual turnaround by driver"] end

subgraph NarrowUnmarked["Curved & Unmarked Roads"] G["Narrow Road with Curbs"] --> H["Vehicle drifts over center line on curves"] I["Unmarked Roadway"] --> J["Oncoming traffic appears"] J --> K["Driver manual takeover"] end ```

- Autopilot executed an unprovoked hard phantom-braking event on the open road. - The test road features standard outer white lines and double yellow center lines. - At 30 mph, Autopilot centered the chassis directly over the double yellow line rather than staying inside the lane.

---

[19:18](https://www.youtube.com/watch?v=UZ1XLqc5IUg&t=1158s) Dead-End Turnaround and Church Tax-Exemption Banter

As the car continues straddling the roadway, the driver approaches a section of the road where local church members are gathered outside selling food. Not wanting to look foolish or cause a scene by letting an autonomous system swerve erratically in front of pedestrians, he takes active control to smoothly navigate past the crowd. Once past the gathering, he reactivates Autopilot to see if it can recover its lane discipline. The vehicle once again drifts completely across the yellow line, putting the car entirely into the oncoming lane. Approaching the physical end of the paved route, the driver observes that the car shows no signs of slowing down or acknowledging the "Dead End" sign ahead, forcing him to intervene before encroaching on a private property boundary marked with "No Trespassing" signs.

Surveying the turnaround point—a rustic, neglected lot littered with aging parked vehicles and abandoned structures—the host notes that this quiet corridor is predominantly lined with rural churches. While turning the car around, he jokes about the tax advantages enjoyed by religious organizations and whimsically pitches an idea for EV enthusiasts: “if you have a church tax free can we make like a Tesla Church electric car Church how's that we can buy tesus tax free.” Turning back in the opposite direction, now with the sun behind him rather than directly blinding the front-facing cameras, the car still fails to hold its lane, drifting directly back over the center line as an oncoming vehicle approaches in the distance.

- The vehicle drifted completely over the double yellow divider into the opposing travel lane. - Autopilot did not decelerate or stop for the dead-end signage at the end of the road. - The area featured minimal traffic due to ongoing church services, offering an isolated environment for testing erratic steering behavior.

---

[21:45](https://www.youtube.com/watch?v=UZ1XLqc5IUg&t=1305s) Narrow Curves and Comparing AP2's Infancy to Early AP1

Heading back along the winding side street, the host analyzes potential reasons why firmware 17.7.2 struggles so severely on this specific stretch. The road is narrower than standard highway lanes and winds through subtle curbs, though the painted lines remain reasonably crisp rather than faded. Even at the modest speed limit of 30 mph, the car repeatedly drifts across the yellow stripe while rounding bends, demonstrating that the system struggles with non-standard road widths and tighter radiuses.

Reflecting on the rough state of the software, the host acknowledges feedback from viewers who watched his previous day's upload, drawing comparisons between this second-generation Autopilot platform (AP2) and the early release cycle of the original Mobileye-based Autopilot (AP1). He explains that when AP1 first launched to customers, it exhibited similar primitive behavior, but rapidly matured through successive over-the-air updates. Looking forward to future improvements, he notes: “so autopilot is in its infancy I think some I you know my video that I posted yesterday somebody said it's the same it looks feels the same right like autopilot one was when it first got released but then they said the good news is that improves quickly from there at least autopilot one did improve quickly from there so that is the hope as well with the this autopilot version two.”

- Non-standard, narrow lane widths with curbs cause the vehicle to wander across the dividing line during 30 mph sweeping turns. - Viewers compared the erratic lane-keeping performance of AP2 firmware 17.7.2 to the initial rough launch of AP1. - Expectation remains that Tesla's internal neural net development will rapidly close the gap, mirroring the fast upgrade curve seen in earlier hardware generations.

---

[23:48](https://www.youtube.com/watch?v=UZ1XLqc5IUg&t=1428s) Unmarked Roads, Camera Mounts, and Future Hands-Off Nag Tests

The test drive proceeds toward a four-way stop where severe solar glare directly impairs the driver's line of sight, making it difficult to judge the arrival order of cross-traffic. Once the intersection clears, he turns onto an unmarked residential road with no painted lines whatsoever. While Autopilot attempts to track the road boundaries on its own and initially does an acceptable job, the driver disengages the system immediately when oncoming traffic approaches, unwilling to gamble on the car's judgment with other motorists nearby. A moment later, after reaching another stop sign and turning back onto a street with clear markings, the Tesla promptly locks onto the visible lane lines without incident.

Wrapping up the video, the driver addresses the production aspects of his testing series, discussing camera angles and mounts. Having tested an improved placement inside the cabin, he shares plans to use an elastic GoPro head strap mount on future drives so viewers can see an authentic driver-perspective view, unconcerned with whether wearing a head strap looks goofy on camera. He also outlines his next specific test: deliberately ignoring the steering wheel "hands-on" alert to document the system's exact abort procedure. Describing his upcoming test agenda, he states, “another thing I want to do is um I wanted to let it basically you know when they show the alert for no hand you know to to hold the wheel if I don't do it I want to test it what happens I know what happens but I want to make sure it happens the way supposed to with this new firmware version.”

- Tested Autopilot on an unmarked road surface with no painted center or edge lines; manual disengagement was required due to approaching opposing vehicles. - Firmware 17.7.2 reacquired lane tracking instantly once standard road markings reappeared past the stop sign. - Upcoming testing planned: evaluating the visual/audible steering wheel nag and the automated lockout protocol when hands remain off the wheel.

## Mentioned Tesla, Tesla Model S, Autopilot, Autopilot 1 (AP1), Autopilot 2 (AP2), Mobileye, Elon Musk, DeRage, GoPro, Amazon

## Video description I wanted to test the latest Tesla Model S autopilot firmware to see what is capable or incapable of doing. There were several fails some expected some not. As an amazon influencer I may earn a commission from qualifying purchases by using this affiliate link.

[Source](https://www.youtube.com/watch?v=UZ1XLqc5IUg)

中文简报

特斯拉Autopilot 17.7.2路测中偏入对向车道 测试表明特斯拉第二代Autopilot固件仍处于初期阶段,在标线褪色和阳光直射炫光下,屡次将中央分流岛误认为车道路径并向路沿偏移。 该视频展示了特斯拉Autopilot固件版本17.7.2在多种高难度环境下的实测表现,涵盖野生动物保护区、狭窄次干道和无标线住宅区道路。在整个行驶过程中,该系统屡次无法保持车道居中,在低速下压上路沿,在时速30英里时骑压双黄中心线,且无视断头路标志。主持人指出,尽管该系统在标准繁忙路段表现尚可,但在应对褪图标线、直射阳光炫光及非标准路宽时表现极其吃力。最后,他将其与AP1早期原始阶段作对比,并提出了未来的测试计划,包括记录车辆的双手脱离方向盘安全锁定机制。 特斯拉Model S的Autopilot固件17.7.2在乡村及保护区道路的车道保持上表现极差,即使在18至19英里的最低时速下也无法顺利通过弯曲的混凝土安全岛。 (0:01) 在限速30英里且划线的双向两车道次干道上,该系统屡次将施划的双黄中央分隔线误认作车道轨迹,骑在道路中央驶向对向车流。 (17:42) 主持人和观众将搭载17.7.2固件的第二代Autopilot(AP2)这种粗糙且不稳定的表现,与初代AP1发布初期的阶段进行了对比,并期待通过OTA快速改善。 (21:45) Autopilot在普通道路上的限速被限制在35英里以下,达到37英里时会立即退出,且未能识别断头路标志或自动红灯刹停。 (17:42)

Detailed notes — zh

## Background 该视频由 YouTube 频道 DeRage 于 2017 年 2 月 26 日发布。视频主要记录了博主对安装在特斯拉 Model S 上的最新 Autopilot 17.7.2 固件进行的实路测试,旨在展示该版本在实际驾驶中能够胜任以及无法处理的各种场景与失误情况。 ## TL;DR 博主在野生动物保护区、狭窄乡间道路、城市主干道及社区支路等多种真实路况下,对特斯拉 Autopilot 17.7.2 固件展开了详尽的极限测试。在褪色标线、强光逆光、弯道以及非标准窄路环境下,系统频繁出现视觉误判、骑线行驶、冲入对向车道及险些撞击路标等严重失效,迫使驾驶员多次紧急人工接管。尽管该版本在主干道跟车平顺且仪表盘界面有所优化,但其在非封闭道路上面临 35 英里/小时的严格限速,且完全不具备红绿灯识别与应对断头路的能力。博主结合自身超过 20 英里的测试经验,指出当前 AP2 仍处于早期雏形阶段,极度依赖清晰标线,寄望其能像初代 AP1 一样通过后续 OTA 固件迅速迭代成熟。 ## Atmosphere & style 整段测试充满了一种近乎“开盲盒”般的紧张与戏剧性,伴随着车辆频频游走在失控边缘的刺激感。博主的语气既无奈又带着一丝苦中作乐的自嘲,在目睹车辆压过中线冲入对向车道或急刹时,时而调侃自己像在酒驾、时而戏谑想建立免税的“特斯拉教堂”。全程的第一视角记录让观众如同坐在副驾,心跳紧随着一次次险情与猛烈的手动纠偏而起伏,真实传达出早期辅助驾驶技术在不完美现实路况下的脆弱与探索感。 ## Bulletin - [07:11](https://www.youtube.com/watch?v=UZ1XLqc5IUg&t=431s) 特斯拉推送的 Autopilot 17.7.2 固件在非封闭道路上面临严格速度限制,自动转向功能限速为 35 英里/小时,超过 37 英里/小时将被强制解除。 - [00:01](https://www.youtube.com/watch?v=UZ1XLqc5IUg&t=1s) 早期 AP2 视觉算法对环境光照及物理标线具有极高依赖性,逆光与老化标线常导致仪表盘虚拟车道严重错位,甚至引导车辆冲出道路或压线逆行。 - [11:35](https://www.youtube.com/watch?v=UZ1XLqc5IUg&t=695s) 该固件版本尚不具备红绿灯主动识别与断头路自动停靠能力,面对窄路、非标中线及完全无标线道路极易失控,需要驾驶员随时准备人工接管。 - [20:44](https://www.youtube.com/watch?v=UZ1XLqc5IUg&t=1244s) 尽管车道保持与几何定位缺陷明显,系统在跟车平顺性及前车静止刹停表现尚可,车主寄望特斯拉通过后续 OTA 像初代 AP1 一样实现快速迭代优化。 ## Key takeaways - [00:01](https://www.youtube.com/watch?v=UZ1XLqc5IUg&t=1s) 在偏僻野生动物保护区测试中,逆光与地面褪色标线导致 Autopilot 无法规划路线,车辆多次冲向路旁草地。 - [00:01](https://www.youtube.com/watch?v=UZ1XLqc5IUg&t=1s) 即便将巡航车速降至系统最低的 18 至 19 英里/小时,系统对老化车道线的感知与定位表现依旧没有任何改善。 - [02:30](https://www.youtube.com/watch?v=UZ1XLqc5IUg&t=150s) 仪表盘 UI 渲染的虚拟车道线与真实道路严重脱节,过弯时经常误判车辆压线或将车直接导向对向逆向车道。 - [05:26](https://www.youtube.com/watch?v=UZ1XLqc5IUg&t=326s) 狭窄乡间道路缺乏宽阔路肩与高反差标线,单目早期视觉算法极易出现横向漂移并游弋至道路正中央。 - [07:11](https://www.youtube.com/watch?v=UZ1XLqc5IUg&t=431s) Autopilot 17.7.2 在普通道路上开启自动转向具有 35 英里/小时的阈值,超过 37 英里/小时会立即强制退出。 - [07:11](https://www.youtube.com/watch?v=UZ1XLqc5IUg&t=431s) 主干道跟车与雷达测距表现相对稳定,即使迎着直射阳光也能平缓识别前车减速并完全刹停。 - [11:35](https://www.youtube.com/watch?v=UZ1XLqc5IUg&t=695s) 社区道路的虚线与弯道让转向决策显得神经质,车辆多次因险些撞上路旁交通标牌而触发紧急人工接管。 - [11:35](https://www.youtube.com/watch?v=UZ1XLqc5IUg&t=695s) 17.7.2 固件完全不具备识别红绿灯信号并自主制动的能力,驾驶员在路口必须自行判断并踩刹车接管。 - [17:42](https://www.youtube.com/watch?v=UZ1XLqc5IUg&t=1062s) 面对双黄线与边缘白线的标准支路,系统反而将中间分道线误认为行驶基准,导致车身长距离骑线逆行。 - [17:42](https://www.youtube.com/watch?v=UZ1XLqc5IUg&t=1062s) 面对尽头的死胡同(Dead End)与禁止侵入标识,系统无减速驻车逻辑,全凭驾驶员目视干预以防驶入废弃私人领地。 - [20:44](https://www.youtube.com/watch?v=UZ1XLqc5IUg&t=1244s) 博主指出 AP2 当时仍处于类似 AP1 早期的‘婴儿期’,表现不稳定但寄希望于车队数据积累后的 OTA 快速改进。 - [22:55](https://www.youtube.com/watch?v=UZ1XLqc5IUg&t=1375s) 在遭遇强烈夕阳逆光盲区及完全无标线的乡村道路时,安全冗余不足迫使驾驶员在迎面来车前迅速解除系统。 ## Detailed walkthrough ### [00:01](https://www.youtube.com/watch?v=UZ1XLqc5IUg&t=1s) 野生动物保护区的初始测试与标线识别失败 视频博主 DeRage 正在测试特斯拉 Model S 上安装的 Autopilot 17.7.2 固件版本。为了给观众提供更清晰的测试视角,他调整了车内的拍摄机位。测试选在一处偏僻的野生动物保护区内部道路展开,由于四周既没有其他社会车辆也没有野生动物,DeRage 认为即使系统出现差错也有足够的草地作为缓冲空间。 ```mermaid flowchart TD accTitle: 野生动物保护区 Autopilot 识别失败流程 accDescr: 展现车辆在面对褪色车道线与减速安全岛时系统的错误行为路径 A["启用 Autopilot (17.7.2 固件)"] --> B{"行经道路安全岛 / 弯道"} B --> C["系统无法识别老化褪色白线"] B --> D["逆光环境严重干扰摄像头视觉"] C --> E["车辆直接偏离车道冲向草地"] D --> E E --> F["驾驶员紧急人工接管纠偏"] ``` 系统在测试一开始便迅速暴露了严重缺陷。当车辆逆着阳光行驶且车道标线终止时,Autopilot 完全手足无措。在遇到道路中央的隔离安全岛时,系统根本无法正确规划路线,导致车辆直接压过车道线冲向旁边的草地,DeRage 不得不多次手动介入拉回方向盘。DeRage 评价道:“I guess it relies a lot on the white line as you guys can see we're also going against the sun which doesn't help very much.” 尽管系统能勉强察觉到路牙(curb),但因为地面的白色标线老化褪色,加上逆光的干扰,车机摄像头对边缘的判断极不准确。即使将车速降至系统允许的最低时速 18 英里至 19 英里左右,对改善系统的识别表现也没有任何帮助。 - 测试环境:偏僻野生动物保护区,无其他社会车辆,地面车道线老化褪色 - 测试固件:特斯拉 Autopilot 17.7.2 - 初始车速控制:测试时速约 19 英里/小时,尝试降至系统最低巡航速度 18 英里/小时,表现均无改善 - 视觉假象:仪表盘显示的虚拟车道线与实际道路位置发生严重偏离,系统在正常行驶时误判车辆偏向右侧或压线 --- ### [02:30](https://www.youtube.com/watch?v=UZ1XLqc5IUg&t=150s) 仪表盘视觉错位与冲入逆向车道 面对保护区弯道,Autopilot 屡次无法通过测试。DeRage 指出,不仅是物理轨迹失控,车机屏幕上渲染的车辆位置也与现实严重脱节。在转弯时,车辆明明正处于车道内,仪表盘却显示车辆处于路中央或已经压线;而在车辆直行时,系统又误认为车道线比实际位置更靠右。 在尝试通过另一处弯道时,虽然系统勉强转了过来,但随即把车直接开进了对向车道正中央。DeRage 带着嘲讽与无奈说道:“He actually did one guys, but you did not help because s do in the left lane, at least it's smart enough to know that's in the wrong place afterwards.” 这一连串的失败证明该版本固件极度依赖清晰的物理标线,且转弯后需要数秒时间才能重新捕捉标线。因为路面坑洼且保护区大门即将关闭,为了避免被反锁在园区内,DeRage 决定手动加速至 30 英里/小时以上驶离该区域,转向外部道路继续测试。 --- ### [05:26](https://www.youtube.com/watch?v=UZ1XLqc5IUg&t=326s) 狭窄乡间道路的标线误判 离开保护区后,DeRage 将车驶入一条较为安静的局部双向窄路。这类道路同样对初代自动辅助驾驶构成了严峻挑战。当车辆启用 Autopilot 后,几乎立刻游弋到道路正中央行驶,完全“无视”两侧的车道边界。 由于后方有其他车辆即将转弯跟上,出于安全考虑,DeRage 迅速接管了方向盘。他特意让观众观察中控仪表盘的显示:即便实际车轮并未压上路边的白色边缘线,系统视觉算法依然错误地判定车辆已经压线。DeRage 强调说:“The camera, it's not very accurate yet as far as like the, you know, knowing where the line is and whatnot cuz it thinks I'm over it right now and I'm not.” 这表明在缺乏宽阔路肩与高反差标线的狭窄路况下,当前的单目/初代辅助驾驶视觉算法仍存在明显的几何定位缺陷。 --- ### [07:11](https://www.youtube.com/watch?v=UZ1XLqc5IUg&t=431s) 繁忙主路测试与车速上限限制 随后车辆驶出路口,进入车流量较大的城市主干道。DeRage 发现,在普通道路上启用 Autopilot 时存在严格的速度阈值限制。当前版本在非封闭道路上的自动转向限速为 35 英里/小时。只要车速超过 35 英里/小时,仪表盘上的可用图标就会直接消失;在实际测试中,车辆在 36 英里/小时下尚能维持,但一旦达到 37 英里/小时便会立刻强制退出。 主干道上的顺畅跟车表现稍稍挽回了评价。即使面对直射的阳光,雷达与摄像头依然成功识别到了前车并平稳刹停。DeRage 提到屏幕车辆显示的一个小细节:UI 修复了部分显示错误,但前车在渲染界面中显示为白色而非蓝色。由于该路段常规车速在 45 英里/小时左右,系统被锁死在 35 英里/小时引起了后方车流的不满,多辆车纷纷变道超车。DeRage 自嘲道:“People going to be seeing, 'Damn electric car so slow, man, them slow autopilots.'” 面对前车即将转弯的情况,考虑到当前固件的侧向侦测能力不足,DeRage 还是选择主动接管踩下刹车。 - 速度限制机制:非高速道路限速 35 英里/小时,超过 35 无法开启,实测 36 英里/小时仍可维持,37 英里/小时强制解除 - 跟车与跟停:在阳光直射下成功识别前车减速与静止,并平缓跟停 - 方向盘握持警报:系统定时发出脱手提示,轻微施加转向扭矩后提示消除 - 界面细节:仪表盘上侦测到的前车渲染为白色目标 --- ### [11:35](https://www.youtube.com/watch?v=UZ1XLqc5IUg&t=695s) 社区道路的虚线困境与红绿灯逻辑 为了避免在主干道阻碍交通,DeRage 拐入了一个安静的居民社区道路。在带有黄色虚线的路段,系统的转向决策表现得非常神经质。车辆在过弯时不断偏向左侧,甚至一度险些直接撞上路边的交通标识牌,迫使驾驶员猛打方向盘干预避让。在标线稍有褪色后,系统便直接提示功能不可用。 DeRage 回忆起前一天的测试表现,认为天气与光照变化对这套视觉系统有着颠覆性的影响。他估算从前一天升级以来,自己已经开启 Autopilot 累计测试了超过 20 英里,某种程度上就像是在“为特斯拉训练车队数据”。然而车辆飘忽不定的走位常常让他感到尴尬,生怕其他驾驶员以为自己在酒驾而报警。在遇到主路红灯时,系统也完全不具备识别红绿灯并主动刹停的能力,必须由驾驶员人工制动。在等待漫长的红灯时,DeRage 看着无车通行的空转绿灯调侃道:“That's why Elon Musk need to work on make it like lights be smarter cuz they're not very smart right now.” 这一阶段的测试充分展现了 17.7.2 固件在应对非标准道路、弱标线以及交通信号灯时的严重局限。 ### [17:42](https://www.youtube.com/watch?v=UZ1XLqc5IUg&t=1062s) 狭窄支路与标线识别失败 特斯拉在接近转弯处时出现了一次突兀且不必要的急刹车。博主随后转向一条支路,准备之后去健身房接自己的儿子。这条道路的标线包括边缘的白线以及路中央的双黄线。博主将车速保持在每小时 30 英里左右,开始测试系统对该路段的应对能力。令人意外的是,尽管人类驾驶员能清晰辨认路面上的标线,Autopilot 却仿佛完全看不见它们。系统没有将车辆保持在车道中央,而是错误地将中间的黄色分道线当作了跟随目标,直接压在道路中线上行驶。 随着车辆驶过在教堂外摆摊卖食物的人群,博主调侃自己不想在路人面前出丑,随后车辆回到了测试最初的起点区域。Autopilot 依旧表现不佳,试图寻找车道中心却屡屡失败,导致车辆彻底越过双黄线,驶入了对向车道。前方出现了一条死胡同(“Dead End”),但车辆并没有任何自主减速或停车的迹象。博主在看到“禁止侵入”(No Trespassing)的告示牌后主动接管,避免开进一处停放着老旧破损车辆的私人废弃场地。 - 车辆在转弯前出现不必要的骤然减速急刹。 - 在时速 30 英里下,Autopilot 无法正确读取双黄线,反而骑在线上居中行驶。 - 面对尽头的断头路与“禁止侵入”标识,系统无法自主识别停车,需人工干预避让。 --- ### [20:44](https://www.youtube.com/watch?v=UZ1XLqc5IUg&t=1244s) 教堂路测试、免税玩笑与 AP2 发展前景 博主掉头折返,指出这处位于住家附近的道路平时布满教堂,但由于教堂礼拜活动尚未结束,整条路上空无一人,是绝佳的测试场地。看到路旁的教堂地产,博主开玩笑调侃道,如果教堂能免税,或许大家可以创立一个“特斯拉教堂”或者“电动汽车教堂”,这样所有人就能免税购买特斯拉了。此时顺光行驶,摄像头视野更加清晰,但车辆依然完全压在分道线上,对面一旦有车驶来就会极度危险,迫使博主随时保持警惕。 针对这一严重偏离车道的现象,博主分析了背后的可能原因:该道路并不是标准宽度的干道,路面偏窄且带有一些弯道,中间的分道虚线虽然没有褪色,但可能不是系统习惯的规范标线。他感叹 Autopilot 2.0 目前仍处于初级阶段,并引用了网友在昨日视频下的留言:“Autopilot is in its infancy I think some I you know my video that I posted yesterday somebody said it's the same it looks feels the same right like autopilot one was when it first got released but then they said the good news is that improves quickly from there at least autopilot one did improve quickly from there so that is the Hope as well with the this autopilot version two.”(我认为 Autopilot 还处于婴儿期。昨天我发的视频底下有人留言说,它现在的表现和感觉就像 Autopilot 1.0 刚发布时一模一样;但好消息是,至少当年 AP1 在那之后迅速获得了改进,所以大家对这个 Autopilot 2.0 版本也抱有同样的希望。) ```mermaid flowchart TD accTitle: AP2 窄路标线识别失效与接管逻辑 accDescr: 展示特斯拉 Autopilot 2.0 在非标窄路上面临的识别困境及驾驶员接管流程 subgraph RoadCondition["道路环境特征"] A["非标准道路:路幅偏窄且有弯道"] B["中间标线清晰但形式特殊"] end subgraph PerceptionFail["系统感知与控制失效"] C["Autopilot 2.0 无法正确锁定车道"] D["车辆误将中心分道线作为行驶基准"] E["车身整体跨过黄线逆行至对向"] end subgraph DriverIntervention["安全接管与预期"] F["对向车辆驶来 / 视线受阻"] G["驾驶员主动接管方向盘"] H["寄望后续 OTA 像 AP1 早期一样快速迭代"] end A --> C B --> C C --> D D --> E E --> F F --> G G --> H ``` --- ### [22:55](https://www.youtube.com/watch?v=UZ1XLqc5IUg&t=1375s) 无标线路段接管与未来测试计划 在接近一个十字路口的四向停车标志(Four-Way Stop)时,博主由于迎着强烈的夕阳直射,几乎看不清比自己先到达路口享有先行权的车辆,只能谨慎等待前车驶离。随后,车辆转入一条博主已知没有任何地面标线的乡村道路。在这个极端场景下,Autopilot 虽然勉强维持了基础行驶,但鉴于前方有对向来车,博主不愿冒任何碰撞风险,立刻手动夺回了车辆控制权。在随后的路口,车辆重新捕捉到了标准清晰的车道标线,巡航表现随即恢复正常。 博主在视频尾声总结了本次测试体验。他坦言视频虽然有点冗长,且展示的功能有限,但记录下了真实的情况。为了改善视频拍摄质量,博主尝试了新的机位,并打算下一次使用 GoPro 的头部头盔绑带支架进行第一人称拍摄,笑称即使戴着头带看起来有点滑稽,但只要画面角度好就无所谓。最后,博主透露了接下来的测试计划:除了继续在其他本地道路进行测试外,他打算专门针对新固件测试“脱手警报”(Hold the Wheel)的惩罚机制,即如果驾驶员完全无视手扶方向盘的警告,验证系统是否会按照规定执行脱离与锁死逻辑。 - 四向停标志处因阳光直射造成视觉盲区,需驾驶员肉眼确认路权。 - 面对完全无标线的道路与对向来车,博主出于安全考虑立即人工接管。 - 下一步计划:使用 GoPro 头带机位测试更多支路,并实测 AP 2.0 固件对长时间脱手驾驶的报警及惩罚逻辑。 ## Mentioned 特斯拉, Model S, Autopilot, Autopilot 17.7.2, Autopilot 2.0, Autopilot 1.0, 埃隆·马斯克, GoPro, DeRage ## Video description I wanted to test the latest Tesla Model S autopilot firmware to see what is capable or incapable of doing. There were several fails some expected some not. As an amazon influencer I may earn a commission from qualifying purchases by using this affiliate link. [Source](https://www.youtube.com/watch?v=UZ1XLqc5IUg)

Original transcript

[0:01] hey guys D raage here so we're going to [0:03] do a [0:04] little um autopilot test I did a video [0:07] yesterday and but I didn't like the [0:10] point of view so you know I changed my [0:12] setup a little bit here see if the uh [0:16] point of view it's a little better for [0:17] you guys so this road is in the middle [0:21] of nowhere [0:22] so and um it's probably going oh look at [0:26] that act up already you did not know [0:29] what to do [0:30] once the lanes uh finish also we're [0:33] going against the sun right now so we're [0:34] doing this test good thing there's [0:37] nobody around us and we're over the line [0:39] already I don't know if you guys can see [0:41] that um we found the middle of the right [0:45] lane now there's this little island over [0:47] here I don't think it'll be able to [0:49] negotiate it and look at that it did not [0:54] negotiate that at all um and obviously I [0:58] just let that happen because are in the [1:00] midd of nowhere it's just grass [1:02] and no Wildlife we harmed we're in a [1:06] Wildlife [1:07] Reserve um and there is nobody else [1:10] around and it can never make this uh [1:12] turn back so it turns from the island is [1:15] notices the curb but uh it basically [1:19] does not find the white line I mean you [1:22] know for this is a old white line you [1:24] know kind of like Fad in and stuff but [1:28] still it should be able to [1:30] to negotiate this turn um I guess it's [1:34] it relies a lot on the white line as you [1:37] guys can see we're also going against [1:39] the sun which doesn't help very [1:42] much let's see I en a little late and [1:46] we're going to D in the grass again [1:48] unless I correct it and we're going like [1:50] you know 19 M an hour uh the lowest the [1:54] we can go is [1:56] 18 which basically is no change [1:59] whatsoever [2:00] but you know I want to do this test I [2:03] don't want to hit the curb U because you [2:07] know that time it looked like it was [2:09] actually going to hit the [2:10] curve so on this road autopilot is not [2:13] working very well um but you know it's [2:16] kind of to be expected I [2:19] suppose so let's see if it's going to do [2:22] this one no I don't want [2:26] them okay [2:30] I think we're going to have to go and [2:31] try in other the roads because this road [2:34] is basically a [2:37] disappointment and if you go fast and [2:39] slow it doesn't doesn't seem to impact [2:43] it all right yeah obviously I wouldn't [2:46] try this in a regular [2:48] road but um and I don't know if you guys [2:51] can see the actual Dash the lines right [2:55] you might be able to see the lines over [2:56] here when we making the [2:58] curve uh he thinks we're in the middle [3:01] of the road when we're not he thinks [3:04] we're like over the line when we're [3:07] not [3:09] so enable [3:12] again [3:15] and he not going to do it I guarantee it [3:18] so that's the state the autopilot is on [3:21] right now oh maybe almost so almost did [3:24] that last one but if you if you notice [3:27] the um on the screen over here you see [3:30] that it [3:31] thinks uh when I'm going the right way [3:34] it thinks the line is further to the [3:40] right and is [3:43] not all right so oh takes a few seconds [3:48] to recognize the lines after the curve [3:52] so let's see this one they all the same [3:56] I mean they all the same um measurement [3:59] and things like that maybe you'll do [4:00] this one yeah actually did this one but [4:03] then we go [4:05] right in the middle of the uh of the [4:08] other line of the other Lane right so he [4:12] actually did one guys uh but you did not [4:15] help because s do in the left [4:18] lane at least it's mud enough to know [4:21] that's in the wrong place afterwards [4:25] right um yeah but that is uh [4:30] what is it [4:32] 17. 7.2 something like that [4:36] forw so I just want to do another video [4:39] probably like drive out of here into [4:42] another local road which no [4:46] traffic and I took control there because [4:48] there was a little uh um bump in the [4:51] road and just for the heck of it let's [4:53] up the speed on this [4:56] one uh I don't go let's see 30 [5:01] no [5:04] yeah [5:08] so uhoh they closed oh no I thought they [5:12] closed the gate on me I was going to say [5:15] no but they Clos the [5:17] entrance I'll be stuck in the [5:19] reservation the Wilderness reservation [5:22] that would not be pretty at all all [5:26] right so let's try on this road this [5:28] road is fairly quiet as well [5:30] it's a very local Road it's a very small [5:32] road too so that is that might be a [5:35] problem in [5:37] itself um it's already going in the [5:39] middle of the road but I'm going to let [5:41] it go [5:42] because I just want to see what it's [5:44] going to do it's right in the middle [5:46] does not see these Lanes at all and [5:49] there's cars behind me now so not behind [5:51] but they're going to turn behind me so [5:54] I'm basically taking [5:56] over so that did not work [6:01] let's [6:04] see yeah and if you look at the display [6:07] I am not over the white line uh in the [6:09] side but it thinks that I [6:11] am so that's what's important the [6:15] camera it's not very um accurate yet as [6:20] far as like the you know knowing where [6:23] the line is and [6:25] whatnot cuz it thinks I'm over it right [6:28] now and I'm not [6:30] I'm close to it but not over the [6:35] line but like I said it's a small not [6:37] not small but like um not a very wide a [6:42] narrow world that's the word I was [6:44] looking [6:46] for so we got to wait for this light [6:50] might take a [6:58] while yay [7:01] imagine [7:03] that you opened [7:07] finally all right now let's see can we [7:11] use it here yeah we can use it [7:14] here but I don't trust here too [7:18] much cuz it's actually a busy [7:23] road one thing I noticed too that if I [7:26] speed above 35 it doesn't disengage [7:28] right away I think if if I go like 36 it [7:32] still works oh no at 37 it [7:37] disengages but I can actually go [7:40] 36 [7:42] without I did it before [7:45] anyways all right so you know right now [7:49] it's on autopilot there's some traffic [7:51] over here so it should [7:54] stop let's pray and it does [7:59] um they fix the bug on the display but [8:02] the cars don't turn blue yet they turn [8:22] white and we're going against the Sun so [8:24] it's working pretty good [8:42] and here we [8:50] go and now he wants me to hold the [8:52] steering [8:53] wheel so we'll do that so he keeps on [8:56] driving happily [9:04] car slowing down in front of us and [9:06] slows down that's [9:15] good yeah so there's some traffic so we [9:17] actually get to use in a normal road and [9:21] it works pretty good in a normal road so [9:24] far [9:33] everybody's passing me though so I got [9:35] to [9:36] go yeah because it's very [9:39] slow 35 is not going to cut in this road [9:44] at least for now for a long [9:50] time people going to be seeing damn [9:52] electric car so slow [9:56] man them slow autopilots [10:01] so there's this road uh that's not [10:03] really a road it's like a [10:05] community just going to go there [10:08] but I mean it is a road but inside of a [10:20] community I'll test for another few [10:23] minutes so we can see how it works I [10:26] want to try this I don't know what's [10:28] going to happen [10:31] but okay going to slow down here [10:35] manually because the car is about to [10:36] turn and the sensor prob wouldn't see [10:40] him not yet not without an [10:51] update okay green [10:55] light even if it wasn't we could turn on [10:57] red thanks Flor [11:00] there it's pretty good so we go [11:04] 35 cuz it is a 45 M hours uh miles an [11:08] hour here but we can actually turn off [11:11] over there and uh yeah we're going to [11:14] take [11:18] over we'll turn off in the uh side roads [11:22] over here then we can test all we want [11:26] and should be very uh quiet as well not [11:29] as busy as [11:35] this so I noticed that right now well [11:38] yeah right now a pilot is not available [11:40] so whenever you go above 35 it doesn't [11:42] even show the option to be [11:49] available okay we're going to turn [11:52] here I think it's another Community but [11:55] there should be some local roads for us [12:03] yeah it is a [12:07] community but don't [12:09] matter we just need to be quiet and [12:17] safe 35 35 [12:20] mile lanes are a little bit [12:24] faded so now it's good let's see is he [12:28] going to turn am [12:30] I yes it [12:33] turned I don't know why but I don't [12:35] trust [12:36] the the single you know the broken down [12:39] whatever it's called the lane the middle [12:41] that's when it's yellow it tends to go [12:44] over for some [12:45] reason like right now it's trying to [12:48] negotiate it trying to figure out but [12:50] it's very much to the [12:56] left and now oh take over there don't [13:00] want to hit the [13:04] sign and now it's not available because [13:07] they're [13:09] fading so one thing I noticed yesterday [13:12] did much better I don't know if it was [13:13] the weather I think it was it could have [13:16] been the [13:17] weather I don't remember if it was [13:19] really sunny I thought it was really [13:20] sunny but yesterday he worked a little [13:23] bit better um [13:25] recognizing um Lanes without actually [13:28] having Lane [13:29] on him today seems to be a little bit [13:32] worse [13:34] see but what are we going to [13:38] do speed up a little bit so we can take [13:41] this [13:43] light cuz we don't want to be waiting [13:47] half an hour [13:48] again these lights can take a [13:55] while all right so 35 again [14:02] as long as there is nobody behind me I [14:04] don't mind [14:06] it and there's two lanes too so they can [14:10] pass oh they [14:12] want so since yesterday I must driven [14:15] like maybe like 20 miles on [14:19] autopilot if I were to [14:24] guess maybe [14:27] more just testing it and you know just [14:31] seeing how he behaves [14:33] and basically training the [14:40] fleet no okay so people must drink I'm [14:46] drunk sometimes cuz I mean drives okay [14:49] but not a perfect driver by any means at [14:56] all so I don't know what people think [14:58] but [14:59] hopefully not that I'm drunk call the [15:02] cops I'm not even driving [15:04] it red light is it going to stop at the [15:07] red light no but why not man it [15:11] should but it won't [15:18] so okay but we stopped [15:44] actually they should have turned here [15:46] but they didn't [16:00] awkward [16:02] silence honestly I don't want people [16:04] think I'm crazy nobody thinks that [16:06] anymore everybody talks some speaker [16:09] phones inside the [16:15] car I remember when Bluetooth first came [16:18] out you thought people were crazy [16:20] talking you know to themselves inside [16:23] the [16:24] car that was a thing nobody used to [16:27] talk you know when Bluetooth renew and [16:41] stuff now once the lane closes then we [16:44] can [16:50] go still green to turn even though [16:54] nobody's going to turn that's why you L [16:57] musk need to work on make it like [17:00] lights be smarter cuz they're not very [17:03] smart right [17:10] now yeah yeah went over the spill limit [17:13] not spill limit but the uh autopilot [17:18] limit yeah this road it's not very good [17:21] for testing at all actually there is no [17:25] roads in here they are very good for [17:27] testing [17:29] um I know this one's not but you know at [17:32] least we got to use it a little [17:34] bit that test was very telling at the uh [17:39] Community well not Community uh the what [17:42] do you call reservation the Disney [17:44] reservation there that was very [17:47] telling oh kind of a hard break there un [17:52] needed but you [17:54] know we're going to turn here again [17:56] we're going to go the side road over [17:58] there and [18:00] uh cuz that's where I have to pick up my [18:02] thumb from the [18:05] gym but I already [18:10] went [18:11] so he just came in [18:15] afterwards all [18:17] right now over [18:19] here let's see what he does cuz it's [18:22] white [18:23] lines now it's double yellow in the [18:26] middle [18:29] okay I can probably speed up a little [18:31] bit yeah oh so this road is interesting [18:34] I I tried this road [18:36] earlier right but we're going 30 m hour [18:40] uh we're still going to go over check [18:41] this out I don't know why but it's like [18:45] does not see those lines at all I don't [18:48] know if you guys can see it I can [18:50] certainly see the [18:52] lines but the car autopilot does not see [18:56] it look at that it goes right in the [18:57] middle it takes us a line to follow the [19:01] bdle it's like okay I should follow this [19:03] line it's right you know keep it in Keep [19:06] It Center keep in the middle but [19:09] no yep and I'm going to go look at this [19:13] guy okay [19:17] lady [19:18] um all right so I'm going to go here [19:21] again there's some people here so I [19:23] don't want to make a fool out of [19:25] myself so I'll drive past the people [19:28] selling food at the [19:31] church and we're back where pretty much [19:34] we started which is the [19:36] reservation all right so now as you can [19:39] see goes in the middle of the lane and [19:41] it tries to figure out but it just [19:42] doesn't do a very good job at [19:45] it and uh we're totally over the yellow [19:50] line and we're over to the other side [19:54] so so I don't know if you guys can see [19:56] that or not but and the end of the road [19:59] it's [20:00] approaching uh I wish you would actually [20:02] stop it you know like it says that end [20:05] right right there right it should but it [20:08] won't but I'll wait a little bit just [20:11] to look at that no transpassing so I [20:15] have to uh you know not going there [20:19] obviously cuz I don't want to TransPass [20:21] it looks like a redneck place as well so [20:25] you [20:27] know like [20:30] old cars and stuff parking in there and [20:33] things like [20:36] that I don't know what this place is to [20:38] be [20:40] honest but there's a abandoned place [20:44] over there it's churches it's a road [20:47] near where we live that's full of [20:51] churches uh but you know it's a good [20:53] place to TK cuz there's nobody around [20:56] yet you know when when services is over [20:59] yes but right now there is [21:02] nobody [21:04] and land Force out over [21:08] there you if you have a church Dex [21:13] free can we make like a Tesla [21:16] Church electric car Church how's [21:20] that we can buy tesus tax free so yeah [21:25] so we're totally over the line hopefully [21:27] you guys can see that [21:29] I'm pretty sure you can it may be easier [21:32] to see now that we're not against the [21:34] Sun and there's a car coming so we [21:38] definitely don't want [21:39] to [21:45] yeah on this Lane uh on this road I [21:49] don't know why I don't know if it's the [21:50] single daugh lines in the middle that [21:54] just doesn't recognize I mean they're [21:55] not [21:56] Faded by any means but it's not of a [22:00] it's kind of a not a standard uh [22:04] Road it's like smaller and not smaller [22:08] you know what do you call it's not as [22:10] wide as narrower than normal so this one [22:14] has a few curbs in [22:16] here and speed liit 30 so we we went [22:20] over the yellow [22:22] again so autopilot is in its infancy I [22:27] think some I you know my video that I [22:29] posted yesterday somebody said it's the [22:31] same it looks feels the same right like [22:35] autopilot one was when it first got [22:38] released but then they said the good [22:40] news is that improves quickly from there [22:42] at least autopilot one did improve [22:45] quickly from there so that is the Hope [22:49] as well with [22:51] the this autopilot version [22:55] two all right so we're going to go [22:59] stop at this fourway stop over [23:01] here and the sun's right in my face I [23:04] cannot see the cars that came in before [23:07] me there he [23:09] goes and we're going to go on this road [23:12] which doesn't have any good markings and [23:15] I know that [23:16] already but let's see what it [23:21] does [23:23] Yep this one has no markings at all um [23:26] it did a pretty good job but I didn't [23:28] want to risk it so it took over because [23:30] there's incoming [23:32] cars [23:35] um over here would probably for sure get [23:42] confused [23:48] now okay another the stop sign so now he [23:51] sees the lane so no you know no surprise [23:55] there follows a good [24:02] all right guys I hopefully you enjoyed [24:05] it's probably a very long video for not [24:08] showing you much but you know I wanted [24:12] to do like a little better angle I [24:15] finally I think I figure out a good [24:17] place to put the camera uh probably [24:19] better than the last [24:21] place I have one of those um you know [24:25] the helmet things for um GoPro so I'll [24:29] try that next time goes in the head it's [24:32] like a headband thing and probably look [24:34] silly and [24:35] but you know as long as it [24:38] gives a good angle I don't really care [24:40] if I look [24:41] silly um and I'll test more in some [24:45] other local roads and um you know let [24:47] you guys know another thing I want to do [24:50] is um I wanted to let it basically you [24:54] know when they show the alert for no [24:58] hand you know to to hold the wheel if I [25:01] don't do it I want to test it what [25:03] happens I know what happens but I want [25:05] to make sure it happens the way supposed [25:07] to with this new firmware version so [25:10] hopefully you guys enjoy like subscribe [25:12] and talk to you guys later bye