Boston Dynamics Cheetah Tops Usain Bolt Peak Sprint at 28.3 MPH
Boston Dynamics
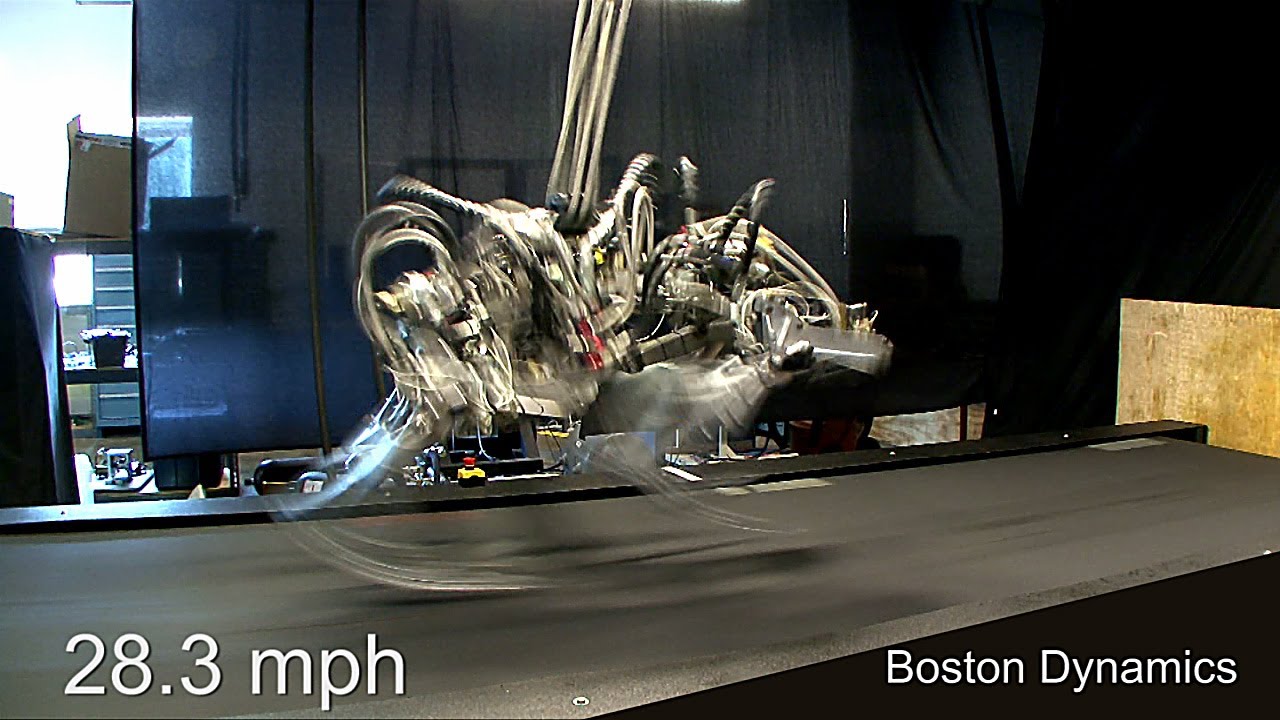
Boston Dynamics demonstrated that its DARPA-funded quadruped can outrun the fastest human split times on a laboratory treadmill, clearing the baseline for untethered outdoor field testing next year.
AI-assisted summary of Cheetah Robot runs 28.3 mph; a bit faster than Usain Bolt — original source. Check the original for full context.
Source published:
Key ideas
- Boston Dynamics' experimental Cheetah robot achieved a peak speed of 28.3 mph during laboratory treadmill trials, breaking its previous record. (0:00)
- The quadruped's top speed surpassed Usain Bolt's peak 20-meter split speed by approximately 0.5 mph. (0:00)
- Funded by DARPA, the treadmill setup uses offboard power to test extreme quadrupedal locomotion, leg coordination, and spine articulation. (0:00)
- Boston Dynamics plans to transition from the tethered treadmill rig to an untethered outdoor variant early next year. (0:00)
Detailed notes
## Background Published on YouTube by Boston Dynamics on September 5, 2012, this demonstration highlights the DARPA-funded Cheetah robot breaking its previous running speed record. According to the description, the quadruped reached 28.3 mph on a treadmill powered by an offboard source, outpacing Usain Bolt's top split speed ahead of planned outdoor untethered testing.
## TL;DR The video documents high-speed laboratory evaluations of Boston Dynamics' experimental Cheetah robot sprinting atop a specialized treadmill. Tethered to an offboard power system, the quadruped successfully accelerates to a peak speed of 28.3 mph, exceeding Usain Bolt's top 20-meter split by roughly 0.5 mph. The trial highlights the platform's advanced leg coordination and spine articulation under high-velocity conditions. This successful run established a baseline for the untethered outdoor variant scheduled for development early the following year.
## Atmosphere & style Propelled by driving, dramatic background music, the video creates an intense and awe-inspiring laboratory atmosphere. Watching the mechanical quadruped sprint at blistering, record-setting speeds delivers a striking sense of raw kinetic power and robotic agility. The demonstration maintains a sharp, focused technical tone before concluding abruptly with a brief, understated spoken 'Thank you.'
## Bulletin - [00:00](https://www.youtube.com/watch?v=chPanW0QWhA&t=0s) Boston Dynamics' experimental Cheetah robot achieved a peak speed of 28.3 mph during laboratory treadmill trials, breaking its previous record. - [00:00](https://www.youtube.com/watch?v=chPanW0QWhA&t=0s) The quadruped's top speed surpassed Usain Bolt's peak 20-meter split speed by approximately 0.5 mph. - [00:00](https://www.youtube.com/watch?v=chPanW0QWhA&t=0s) Funded by DARPA, the treadmill setup uses offboard power to test extreme quadrupedal locomotion, leg coordination, and spine articulation. - [00:00](https://www.youtube.com/watch?v=chPanW0QWhA&t=0s) Boston Dynamics plans to transition from the tethered treadmill rig to an untethered outdoor variant early next year.
## Key takeaways - [00:00](https://www.youtube.com/watch?v=chPanW0QWhA&t=0s) Cheetah is an experimental quadruped robot engineered by Boston Dynamics. - [00:00](https://www.youtube.com/watch?v=chPanW0QWhA&t=0s) The development and testing of the Cheetah platform received funding support from DARPA. - [00:00](https://www.youtube.com/watch?v=chPanW0QWhA&t=0s) The robot reached a peak sprinting speed of 28.3 mph on a specialized treadmill. - [00:00](https://www.youtube.com/watch?v=chPanW0QWhA&t=0s) At 28.3 mph, the robot ran approximately 0.5 mph faster than Usain Bolt's fastest 20-meter split. - [00:00](https://www.youtube.com/watch?v=chPanW0QWhA&t=0s) The current laboratory iteration relies on an offboard power source rather than onboard batteries. - [00:00](https://www.youtube.com/watch?v=chPanW0QWhA&t=0s) Tethering and laboratory treadmill setups allow researchers to safely study extreme quadrupedal running dynamics. - [00:00](https://www.youtube.com/watch?v=chPanW0QWhA&t=0s) The platform serves as an experimental testbed for high-speed leg coordination and spine articulation. - [00:00](https://www.youtube.com/watch?v=chPanW0QWhA&t=0s) The high-speed indoor trials establish a performance baseline for future untethered legged robots. - [00:00](https://www.youtube.com/watch?v=chPanW0QWhA&t=0s) Boston Dynamics scheduled outdoor testing of a free-running, untethered version to begin early the following year.
## Detailed walkthrough ### [00:00](https://www.youtube.com/watch?v=chPanW0QWhA&t=0s) Cheetah Robot Sets High-Speed Quadruped Record
The demonstration opens with driving, dramatic music as Boston Dynamics showcases the Cheetah robot during high-speed laboratory trials. Developed with funding support from DARPA (Defense Advanced Research Projects Agency), the experimental quadruped is shown sprinting atop a specialized treadmill with an offboard power source. The trial documents the machine accelerating beyond its previous performance marks, ultimately reaching a top speed of 28.3 mph—roughly 0.5 mph faster than Usain Bolt's peak 20-meter split speed—before the video concludes with the brief spoken closing, “Thank you.”
This laboratory treadmill configuration serves as an experimental testbed for evaluating extreme quadrupedal locomotion, spine articulation, and leg coordination under offboard tethering. The high-speed milestone marks the final phase before moving the platform outside, with Boston Dynamics preparing to initiate testing on an untethered, free-running outdoor variant early the following year.
- **Developer & Funding**: Engineered by Boston Dynamics under funding from DARPA. - **Peak Velocity**: Reached a top speed of 28.3 mph, surpassing the human running record set across Usain Bolt's fastest 20-meter split by approximately 0.5 mph. - **Testing Setup**: Operated on an indoor treadmill rig supported by offboard power and safety tethers. - **Development Roadmap**: Serves as the development baseline ahead of untethered outdoor field testing planned for early next year.
## Mentioned Boston Dynamics, Cheetah Robot, DARPA, Usain Bolt
## Video description Cheetah Robot is a fast-running quadruped developed by Boston Dynamics with funding from DARPA. It just blazed past its previous speed record, getting up to 28.3 mph, about 0.5 mph faster than Usain Bolt's fastest 20 meter split. This version of the Cheetah Robot runs on a treadmill with offboard power. Testing on an untethered outdoor version starts early next year. For more information about Cheetah or the other robots we develop, visit www.BostonDynamics.com.
[Source](https://www.youtube.com/watch?v=chPanW0QWhA)