TU Wien Validates Triple Pendulum Swing-Up via Feedforward Control
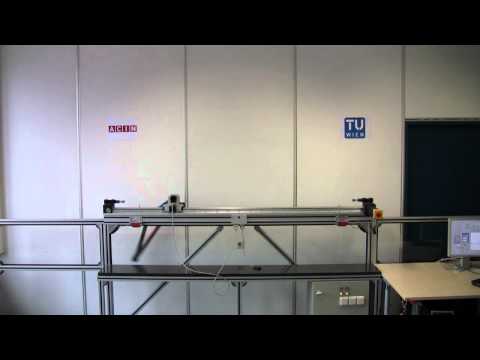
Triple Pendulum on a Cart — Tobias Glück

Tobias Glück

Combining constrained feedforward with optimal feedback control enables physical stabilization and swing-up of a multi-link pendulum on a moving cart.

AI-assisted summary of Triple Pendulum on a Cart — original source. Check the original for full context.

Source published:

Key ideas

  • Researchers at TU Wien demonstrate successful experimental swing-up and swing-down control of a triple pendulum on a cart. (0:00)
  • The experimental setup uses a two-degrees-of-freedom control architecture combining constrained feedforward with optimal feedback control.
  • Developed by Andreas Eder and Tobias Glück, the control methodology was subsequently published and validated in the journal Automatica.

Detailed notes

## Background Published on YouTube by Tobias Glück on March 29, 2011, this video presents research conducted alongside Andreas Eder at TU Wien's ACIN CDS. According to the description, the demonstration exhibits a two-degrees-of-freedom design utilizing constrained feedforward and optimal feedback control to achieve the swing-up and swing-down of a triple pendulum on a cart.

## TL;DR The video provides a brief, non-narrated visual record of an experimental laboratory setup demonstrating control theory in practice. Without spoken dialogue, the footage captures the cart manipulating the triple pendulum through its swing-up and swing-down routines. The brief demonstration concludes simply with a final title card stating 'The End.'

## Atmosphere & style The presentation is purely technical, clinical, and quiet, absent of any voiceover commentary or dramatic production elements. It feels like an unembellished archival laboratory recording designed solely to showcase mechanical precision and control engineering. The mood is steady and understated, culminating in an abrupt, functional visual sign-off.

## Bulletin - [00:00](https://www.youtube.com/watch?v=cyN-CRNrb3E&t=0s) Researchers at TU Wien demonstrate successful experimental swing-up and swing-down control of a triple pendulum on a cart. - The experimental setup uses a two-degrees-of-freedom control architecture combining constrained feedforward with optimal feedback control. - Developed by Andreas Eder and Tobias Glück, the control methodology was subsequently published and validated in the journal Automatica.

## Key takeaways - [00:00](https://www.youtube.com/watch?v=cyN-CRNrb3E&t=0s) The demonstration presents experimental control for a multi-link triple pendulum system mounted on a linear cart. - The control system successfully executes both full swing-up maneuvers and controlled swing-down operations. - A two-degrees-of-freedom design framework governs the dynamic motion of the cart and pendulum links. - Constrained feedforward control is implemented to steer the system along feasible dynamic trajectories within mechanical limits. - Optimal feedback control is incorporated to maintain stability and counteract disturbances during critical phases. - The experimental apparatus and validation were conducted at TU Wien's Automation and Control Institute (ACIN CDS). - The control implementation was executed by researchers Andreas Eder and Tobias Glück. - Theoretical formulation and experimental validation are detailed in the 2013 Automatica paper by Glück, Eder, and Kugi.

## Detailed walkthrough ### [00:00](https://www.youtube.com/watch?v=cyN-CRNrb3E&t=0s) Demonstration Conclusion

The video concludes its visual presentation of the experimental setup, with the auto-generated transcript capturing only the final closing title card: “The End.” The recording serves as a concise experimental demonstration of the swing-up and swing-down control for a triple pendulum on a cart without any spoken commentary or dialogue throughout the run.

## Mentioned Tobias Glück, Andreas Eder, Andreas Kugi, TU Wien, ACIN CDS, Automatica

## Video description Triple Pendulum on a Cart Swing-up and Swing-down

Two-degrees-of-freedom design: Constrained feedforward & optimal feedback control

TU Wien ACIN CDS http://www.acin.tuwien.ac.at/

Done by Andreas Eder and Tobias Glück

Publications: Glück T., Eder A., and Kugi A: Swing-up control of a triple pendulum on a cart with experimental validation. Automatica, vol. 49, no. 3, pp. 801-808, 2013. http://www.sciencedirect.com/science/article/pii/S000510981200605X

[Source](https://www.youtube.com/watch?v=cyN-CRNrb3E)

中文简报

维也纳工业大学通过前馈控制验证三重摆起摆 将受限前馈与最优反馈控制相结合,实现了移动小车上多连杆摆的物理稳定与起摆。 该视频简要记录了展示控制理论实际应用的实验室实验装置,未包含旁白解说。在没有口头对话的情况下,画面捕捉到小车操控三重摆完成起摆和下落程序的全过程。这段简短的演示最后仅以一张写有“The End”的片尾卡片结束。 维也纳工业大学的研究人员展示了小车上三重摆起摆与下落控制的成功实验。 (0:00) 该实验装置采用了双自由度控制架构,将受限前馈与最优反馈控制相结合。 该控制方法由Andreas Eder和Tobias Glück开发,随后在《Automatica》期刊上发表并得到验证。

Detailed notes — zh

## Background 该视频由 Tobias Glück 于 2011 年 3 月 29 日发布在 YouTube 平台上。视频展示了维也纳工业大学自动化与控制研究所(TU Wien ACIN CDS)Andreas Eder 与 Tobias Glück 合作开展的小车三摆(Triple Pendulum on a Cart)实验,主要演示了基于两自由度控制设计(受约束前馈控制与最优反馈控制)实现的三摆起摆与回摆控制过程,相关论文已发表于控制领域权威期刊《Automatica》。 ## TL;DR 视频记录了经典复杂非线性欠驱动系统——小车三摆的完整动态控制实验。实验中小车在水平轨道上通过精准规划的加减速往复运动,将完全处于自然下垂状态的三阶摆杆迅速驱动起摆(Swing-up)。在达到最高垂直位置后,控制系统成功克服高度不稳定特性,使三节摆杆精准竖直倒立并稳定平衡。最终,小车再次协调动作,平稳引导三阶摆受控回摆(Swing-down)至初始静止状态。 ## Atmosphere & style 整个视频呈现出高度严谨、克制的实验室硬核科研氛围。没有多余的人声解说或背景音乐,画面聚焦于机械结构在轨道上利落流畅的运动与摆动,带有一种纯粹且极具观赏性的工程美感。从起摆时剧烈的非线性摆动,到瞬间定格在垂直平衡点的极致精准,整个过程带给观众强烈的视觉震撼与理工科特有的掌控秩序感。 ## Bulletin - [00:00](https://www.youtube.com/watch?v=cyN-CRNrb3E&t=0s) 维也纳工业大学(TU Wien ACIN CDS)团队成功实现小车三摆(Triple Pendulum on a Cart)从完全下垂状态到垂直平衡的全自动起摆与回摆物理实验验证。 - [00:00](https://www.youtube.com/watch?v=cyN-CRNrb3E&t=0s) 控制系统采用两自由度架构,将受约束前馈控制与最优反馈控制有机结合,兼顾轨迹规划与平衡点稳定。 - [00:00](https://www.youtube.com/watch?v=cyN-CRNrb3E&t=0s) 该方案有效克服了高阶欠驱动多体系统的强非线性及输入约束难题,相关成果发表于国际控制顶级期刊《Automatica》。 ## Key takeaways - [00:00](https://www.youtube.com/watch?v=cyN-CRNrb3E&t=0s) 小车三摆系统是一个具有高度非线性和欠驱动特性的复杂多体动力学实验平台。 - [00:00](https://www.youtube.com/watch?v=cyN-CRNrb3E&t=0s) 该项研究由维也纳工业大学自动化与控制研究所(TU Wien ACIN CDS)的研究人员 Andreas Eder 与 Tobias Glück 合作完成。 - [00:00](https://www.youtube.com/watch?v=cyN-CRNrb3E&t=0s) 核心算法采用两自由度控制架构(Two-degrees-of-freedom design),解耦前馈轨迹规划与反馈镇定。 - [00:00](https://www.youtube.com/watch?v=cyN-CRNrb3E&t=0s) 受约束前馈控制(Constrained feedforward control)负责在满足执行器物理约束的条件下规划最优过渡起摆轨迹。 - [00:00](https://www.youtube.com/watch?v=cyN-CRNrb3E&t=0s) 最优反馈控制(Optimal feedback control)在倒立平衡点附近生效,确保小车和各级摆杆达到鲁棒渐进稳定。 - [00:00](https://www.youtube.com/watch?v=cyN-CRNrb3E&t=0s) 实验完整演示了小车三摆从自然下垂静止、经过精准加减速大范围摆动起摆(Swing-up)至垂直向上的全过程。 - [00:00](https://www.youtube.com/watch?v=cyN-CRNrb3E&t=0s) 在实现顶部倒立平衡稳定后,系统展示了平稳受控的回摆(Swing-down)动作。 - [00:00](https://www.youtube.com/watch?v=cyN-CRNrb3E&t=0s) 相关学术论文已发表于控制期刊《Automatica》(2013年第49卷第3期),题为《Swing-up control of a triple pendulum on a cart with experimental validation》。 ## Detailed walkthrough ### [00:00](https://www.youtube.com/watch?v=cyN-CRNrb3E&t=0s) 小车三摆系统的起摆与稳定控制演示 本视频展示了维也纳工业大学自动化与控制研究所(TU Wien ACIN CDS)所开展的经典非线性控制实验——小车三摆(Triple Pendulum on a Cart)。该研究由 Andreas Eder 与 Tobias Glück 共同完成,核心目标是解决这一具有高度非线性与欠驱动特性的复杂多体系统的动力学控制难题。视频记录了小车通过水平轨道上的精准加减速运动,驱动悬挂在小车上的三阶倒立摆从完全下垂状态迅速完成起摆(Swing-up),并在最高垂直平衡位置实现稳定倒立控制,随后平稳受控回摆(Swing-down)的全过程。 整个系统的核心控制算法基于两自由度控制架构(Two-degrees-of-freedom design),将受约束前馈控制(Constrained feedforward control)与最优反馈控制(Optimal feedback control)有机结合。前馈部分用于规划满足输入约束的最优过渡轨迹,反馈部分则保证小车及摆杆在平衡点附近的鲁棒渐进稳定。相关学术成果发表于期刊《Automatica》(题为《Swing-up control of a triple pendulum on a cart with experimental validation》)。视频为纯实验过程记录,未包含任何口头解说,转录文本仅在结尾处出现了唯一的文字提示:“The End.” ```mermaid flowchart LR accTitle: 两自由度控制架构示意图 accDescr: 展示受约束前馈与最优反馈控制作用于小车三摆系统的控制框图 subgraph Control["两自由度控制设计"] FF["受约束前馈控制<br/>Constrained Feedforward"] FB["最优反馈控制<br/>Optimal Feedback"] end System["小车三摆实验装置<br/>Triple Pendulum on a Cart"] FF --> System System --> FB FB --> System ``` - 研究机构与人员:维也纳工业大学自动化与控制研究所复杂动态系统研究组(TU Wien ACIN CDS),由 Andreas Eder 与 Tobias Glück 合作开发。 - 控制策略:两自由度设计(Two-degrees-of-freedom design),包含受约束前馈规划与最优反馈稳定控制。 - 运动过程:小车三摆从自然下垂静止状态出发,经历大范围摆动起摆(Swing-up)、顶部直立平衡稳定以及受控回摆(Swing-down)。 - 学术出版物:Glück T., Eder A., and Kugi A: *Swing-up control of a triple pendulum on a cart with experimental validation*. *Automatica*, vol. 49, no. 3, pp. 801-808, 2013. ## Mentioned Tobias Glück, Andreas Eder, Andreas Kugi, 维也纳工业大学自动化与控制研究所(TU Wien ACIN CDS), 《Automatica》, 《Swing-up control of a triple pendulum on a cart with experimental validation》, 小车三摆系统(Triple Pendulum on a Cart) ## Video description Triple Pendulum on a Cart Swing-up and Swing-down Two-degrees-of-freedom design: Constrained feedforward & optimal feedback control TU Wien ACIN CDS http://www.acin.tuwien.ac.at/ Done by Andreas Eder and Tobias Glück Publications: Glück T., Eder A., and Kugi A: Swing-up control of a triple pendulum on a cart with experimental validation. Automatica, vol. 49, no. 3, pp. 801-808, 2013. http://www.sciencedirect.com/science/article/pii/S000510981200605X [Source](https://www.youtube.com/watch?v=cyN-CRNrb3E)

Original transcript

[0:00] The End .