Boston Dynamics Runs DARPA-Backed WildCat Robot at 19 MPH
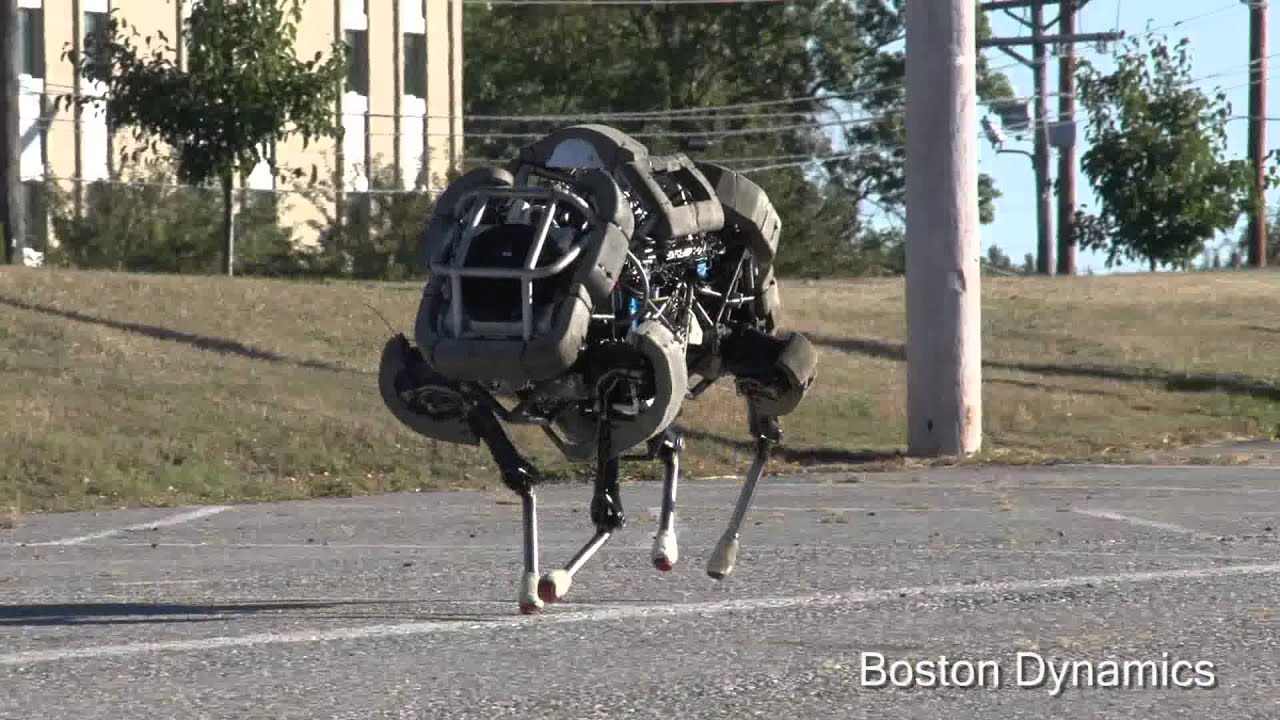
Boston Dynamics
Field tests under DARPA's M3 program demonstrate that quadruped robots can reach 19 mph on flat ground by employing dynamic bounding and galloping gaits.
AI-assisted summary of Introducing WildCat — original source. Check the original for full context.
Source published:
Key ideas
- Boston Dynamics introduced WildCat, a four-legged robotic platform engineered to run at high speeds across varied terrain. (0:00)
- The platform achieved a top speed of approximately 19 mph (around 30 km/h) on flat terrain using bounding and galloping gaits. (0:00)
- Development of WildCat was funded through DARPA's Maximum Mobility and Manipulation (M3) program to advance dynamic leg mobility and stability. (0:00)
Detailed notes
## Background Published on YouTube by Boston Dynamics on October 4, 2013, "Introducing WildCat" presents field testing of their autonomous four-legged robotic platform. According to the video description, the robot was developed with funding from DARPA's M3 program to achieve rapid locomotion across diverse terrains, reaching speeds of approximately 19 mph on flat ground using bounding and galloping gaits.
## TL;DR The video provides a direct performance demonstration of Boston Dynamics' WildCat quadruped robot maneuvering across an open paved surface. Funded under DARPA's Maximum Mobility and Manipulation (M3) program, the machine showcases dynamic balance, rapid acceleration, and sharp turns. Throughout the footage, WildCat reaches speeds of up to roughly 19 mph, seamlessly transitioning between bounding and galloping gaits to sustain stability.
## Atmosphere & style The presentation carries an austere, utilitarian field-test aesthetic completely devoid of voiceover narration, musical score, or polished studio staging. Instead, the footage is dominated by the aggressive roar of an onboard combustion engine and the rhythmic clattering of metallic limbs striking the asphalt. Watching the machine gallop, bank into turns, and correct its balance feels visceral and startling, evoking a raw encounter with an uncanny, bio-inspired technological prototype.
## Bulletin - [00:00](https://www.youtube.com/watch?v=wE3fmFTtP9g&t=0s) Boston Dynamics introduced WildCat, a four-legged robotic platform engineered to run at high speeds across varied terrain. - [00:00](https://www.youtube.com/watch?v=wE3fmFTtP9g&t=0s) The platform achieved a top speed of approximately 19 mph (around 30 km/h) on flat terrain using bounding and galloping gaits. - [00:00](https://www.youtube.com/watch?v=wE3fmFTtP9g&t=0s) Development of WildCat was funded through DARPA's Maximum Mobility and Manipulation (M3) program to advance dynamic leg mobility and stability.
## Key takeaways - [00:00](https://www.youtube.com/watch?v=wE3fmFTtP9g&t=0s) WildCat is an autonomous quadruped robot designed for rapid locomotion across diverse terrain types. - [00:00](https://www.youtube.com/watch?v=wE3fmFTtP9g&t=0s) The project received funding and support under DARPA's Maximum Mobility and Manipulation (M3) program. - [00:00](https://www.youtube.com/watch?v=wE3fmFTtP9g&t=0s) During flat-terrain field trials, WildCat demonstrated speeds reaching approximately 19 mph. - [00:00](https://www.youtube.com/watch?v=wE3fmFTtP9g&t=0s) The robot utilizes dynamic bounding gaits to sustain stability and balance at high velocity. - [00:00](https://www.youtube.com/watch?v=wE3fmFTtP9g&t=0s) Galloping locomotion enables the platform to rapidly accelerate and maneuver through turns. - [00:00](https://www.youtube.com/watch?v=wE3fmFTtP9g&t=0s) The demonstration captured the platform's peak field performance up to the time of release. - [00:00](https://www.youtube.com/watch?v=wE3fmFTtP9g&t=0s) The trial highlights advancements in dynamic mechanical stability and powered quadrupedal locomotion. - [00:00](https://www.youtube.com/watch?v=wE3fmFTtP9g&t=0s) The platform operates with onboard mechanical and engine propulsion without tethered assistance during the run.
## Detailed walkthrough ### [00:00](https://www.youtube.com/watch?v=wE3fmFTtP9g&t=0s) Demonstration of the WildCat Quadruped Robot
Boston Dynamics introduces WildCat, an autonomous four-legged robot engineered to operate and run at high speeds across all types of terrain. Developed with funding provided by DARPA’s Maximum Mobility and Manipulation (M3) program, the platform is designed to test dynamic leg mobility, stability, and high-speed locomotion. The demonstration documents WildCat's best field performance, showing the robot maneuvering on flat ground and reaching speeds of approximately 19 mph (around 30 km/h).
Throughout the run, the quadruped relies on distinct bounding and galloping gaits to maintain stability, execute turns, and rapidly accelerate. The audio track consists primarily of the mechanical and engine sounds of the robotic platform in motion, with no spoken dialogue present in the source track beyond the concluding subtitle attribution text: “Thank you you Субтитры создавал DimaTorzok Продолжение следует...”
- **Developer:** Boston Dynamics - **Funding Program:** DARPA M3 (Maximum Mobility and Manipulation) program - **Platform Type:** High-speed four-legged (quadrupedal) robot - **Top Speed Shown:** Approximately 19 mph on flat terrain - **Locomotion Modes:** Bounding and galloping gaits
## Mentioned WildCat, Boston Dynamics, DARPA, DARPA M3 (Maximum Mobility and Manipulation) program
## Video description WildCat is a four-legged robot being developed to run fast on all types of terrain. So far WildCat has run at about 19 mph on flat terrain using bounding and galloping gaits. The video shows WildCat's best performance so far. WildCat is being developed by Boston Dynamics with funding from DARPA's M3 program. For more information about WIldCat visit our website at www.BostonDynamics.com.
[Source](https://www.youtube.com/watch?v=wE3fmFTtP9g)