Ball Aerospace JWST Actuator Uses Flexure Train for 2-Nm Steps
Breaking Taps
A single stepper motor achieves both 21-millimeter travel and 2-nanometer resolution open-loop by combining an intentional 320-degree backlash coupling with a monolithic flexure motion divider.
AI-assisted summary of How to achieve nanometer precision in space? — original source. Check the original for full context.
Source published:
Key ideas
- The James Webb Space Telescope uses 108 cryogenic actuators built by Ball Aerospace to align its 18 hexagonal primary mirror segments across six kinematic degrees of freedom with nanometer precision. (0:00)
- Each actuator integrates both a coarse stage providing 21 mm of travel with 58 nm steps and a fine stage offering 10 µm of travel with 2 nm step resolution, all within a 600 g package. (2:11)
- A single stepper motor operates both stages without active closed-loop power, using an intentional 320° deadband pin coupling to toggle between coarse ball screw drive and fine planar flexure displacement. (6:47)
- To prevent the moving assembly from rotating around the ball screw, the design utilizes an external flexure linkage as a torsional stabilizer that allows linear movement while resisting rotation. (8:37)
Detailed notes
## Background Published on YouTube by the engineering channel Breaking Taps on February 7, 2022, this video explores the cryogenic mirror actuators developed for the James Webb Space Telescope. According to the description, the piece investigates how these devices achieve long travel and nanometer precision while surviving launch vibrations, extreme cold, and hard vacuum using intricate flexure mechanisms.
## TL;DR To properly focus light onto its scientific instruments, the James Webb Space Telescope relies on 108 cryogenic actuators across its 18 hexagonal primary mirror segments, operating in hexapod configurations to provide six kinematic degrees of freedom. Built by Ball Aerospace, each actuator achieves both a 21 mm coarse travel stage with 58 nm resolution and a 10 µm fine adjustment stage capable of 2 nm per step using a single internal stepper motor. The system avoids active heat-generating feedback by chaining planetary and spur gear reductions into an offset camshaft that drives a monolithic planar flexure motion divider. Furthermore, a clever pin-coupling lost-motion mechanism with roughly 320° of backlash allows the single motor to alternate between fine flexure adjustments and coarse ball screw actuation without adding weight or thermal penalties.
## Atmosphere & style The presentation carries the enthusiastic, analytical vibe of an inquisitive maker reverse-engineering elite aerospace hardware at a home workbench. The host's delivery blends genuine reverence for Ball Aerospace's engineering solutions with casual, dry humor about the practical headaches of 3D printing flight-spec tolerances on consumer machines. It feels less like an academic lecture and more like a hands-on mechanical teardown, guiding the viewer from awe at the brutal environmental constraints of deep space into pure appreciation for the clever simplicity of gears and flexures.
## Bulletin - [00:00](https://www.youtube.com/watch?v=5MxH1sfJLBQ&t=0s) The James Webb Space Telescope uses 108 cryogenic actuators built by Ball Aerospace to align its 18 hexagonal primary mirror segments across six kinematic degrees of freedom with nanometer precision. - [02:11](https://www.youtube.com/watch?v=5MxH1sfJLBQ&t=131s) Each actuator integrates both a coarse stage providing 21 mm of travel with 58 nm steps and a fine stage offering 10 µm of travel with 2 nm step resolution, all within a 600 g package. - [06:47](https://www.youtube.com/watch?v=5MxH1sfJLBQ&t=407s) A single stepper motor operates both stages without active closed-loop power, using an intentional 320° deadband pin coupling to toggle between coarse ball screw drive and fine planar flexure displacement. - [08:37](https://www.youtube.com/watch?v=5MxH1sfJLBQ&t=517s) To prevent the moving assembly from rotating around the ball screw, the design utilizes an external flexure linkage as a torsional stabilizer that allows linear movement while resisting rotation.
## Key takeaways - [00:00](https://www.youtube.com/watch?v=5MxH1sfJLBQ&t=0s) The primary mirror assembly requires aligning 18 hexagonal segments into a single parabolic contour across seven degrees of freedom. - [00:35](https://www.youtube.com/watch?v=5MxH1sfJLBQ&t=35s) Six spatial degrees of freedom (tip, tilt, roll, and X, Y, Z translation) are driven by a hexapod arrangement of six actuators per mirror, while radius of curvature is adjusted separately. - [01:12](https://www.youtube.com/watch?v=5MxH1sfJLBQ&t=72s) Actuators must survive launch vibrations, operate in hard vacuum and cryogenic temperatures, and hold positions indefinitely without active power emitting heat near the cold optics. - [02:11](https://www.youtube.com/watch?v=5MxH1sfJLBQ&t=131s) The Ball Aerospace flight unit provides 21 mm of coarse travel (58 nm resolution) and 10 µm of fine travel (2 nm resolution) at roughly 600 grams mass and 150 mm in length. - [04:04](https://www.youtube.com/watch?v=5MxH1sfJLBQ&t=244s) The fine positioning stage achieves 2 nm step resolution open-loop using a compound reduction chain of a 1:60 planetary gear, a 3:1 spur gear, and a planar flexure joint. - [04:58](https://www.youtube.com/watch?v=5MxH1sfJLBQ&t=298s) The monolithic flexure functions as a mechanical motion divider, converting roughly 1 mm of camshaft displacement at the center into just a few microns of travel at the mounting interface. - [06:47](https://www.youtube.com/watch?v=5MxH1sfJLBQ&t=407s) A lost-motion pin coupler with roughly 320° of rotational backlash allows the same motor to adjust the fine stage without engaging the coarse drive mechanism. - [07:36](https://www.youtube.com/watch?v=5MxH1sfJLBQ&t=456s) Driving past the pin coupler's deadband engages a 1:8 reduction gear and a precision ball screw to translate the coarse positioning stage over its full 21 mm travel range. - [08:05](https://www.youtube.com/watch?v=5MxH1sfJLBQ&t=485s) Reversing motor direction immediately disengages coarse translation, re-establishing fine adjustment within the new coarse position. - [08:37](https://www.youtube.com/watch?v=5MxH1sfJLBQ&t=517s) An external flexure-based torsional stabilizer prevents the actuator body from spinning about the ball screw while accommodating axial travel. - [09:08](https://www.youtube.com/watch?v=5MxH1sfJLBQ&t=548s) Coordinated extension and retraction across the six Stewart platform actuators fully defines each mirror segment's kinematic position.
## Detailed walkthrough ### [00:00](https://www.youtube.com/watch?v=5MxH1sfJLBQ&t=0s) The Engineering Marvel of JWST Mirror Actuators
The James Webb Space Telescope is packed with cutting-edge technology, from a tennis-court-sized sunshield thinner than a human hair to specialized cryocoolers and ultra-lightweight mirrors. Yet, the single most impressive piece of engineering on the entire observatory is its mirror actuator system. The primary mirror consists of 18 hexagonal segments that must unite into a seamless, concave ellipsoid to properly focus light into scientific instruments.
Aligning these mirrors requires positioning each segment across seven degrees of freedom to nanometer precision—a feat that is extraordinarily difficult on Earth, let alone in deep space. Six kinematic degrees of freedom are controlled directly by these actuators: tip, tilt, roll, X translation, Y translation, and Z translation (piston). The seventh degree of freedom—the radius of curvature of each mirror segment—is handled by a separate actuator.
Beyond sheer mechanical precision, the operational constraints are brutal. The actuators must survive the violent vibrations of a rocket launch, followed by the hard vacuum and cryogenic temperatures of deep space. They must be as lightweight as possible while retaining sufficient stiffness to hold nanometer positions indefinitely. Furthermore, because components behind the sunshield can thermally radiate and disrupt mirror performance, the actuators must remain completely cold—meaning they cannot rely on continuous, heat-emitting active power to hold their position. Regarding this staggering list of constraints, the host remarks: “This is like an impossible set of engineering problems to solve and yet it has been solved which is just truly remarkable to me.”
- **Developer:** Ball Aerospace designed and manufactured the actuators. - **Total Deployed Actuators:** 108 units across the primary mirror assembly (6 actuators per segment). - **Architecture:** 6 actuators per hexagonal segment arranged in a hexapod (Stewart platform).
---
[02:11](https://www.youtube.com/watch?v=5MxH1sfJLBQ&t=131s) Actuator Specifications and 3D Printed Replica
The operational specifications achieved by Ball Aerospace are staggering considering the size and mass constraints of space hardware. The unit provides both massive macro-level travel and extreme micro-level refinement:
| Specification | Coarse Stage | Fine Stage | |:--- |:--- |:--- | | **Travel Range** | 21 mm (~2 cm) | 10 µm | | **Step Resolution** | 58 nm | 2 nm | | **Mass** | ~600 g (~1.5 lbs) total unit mass | — |
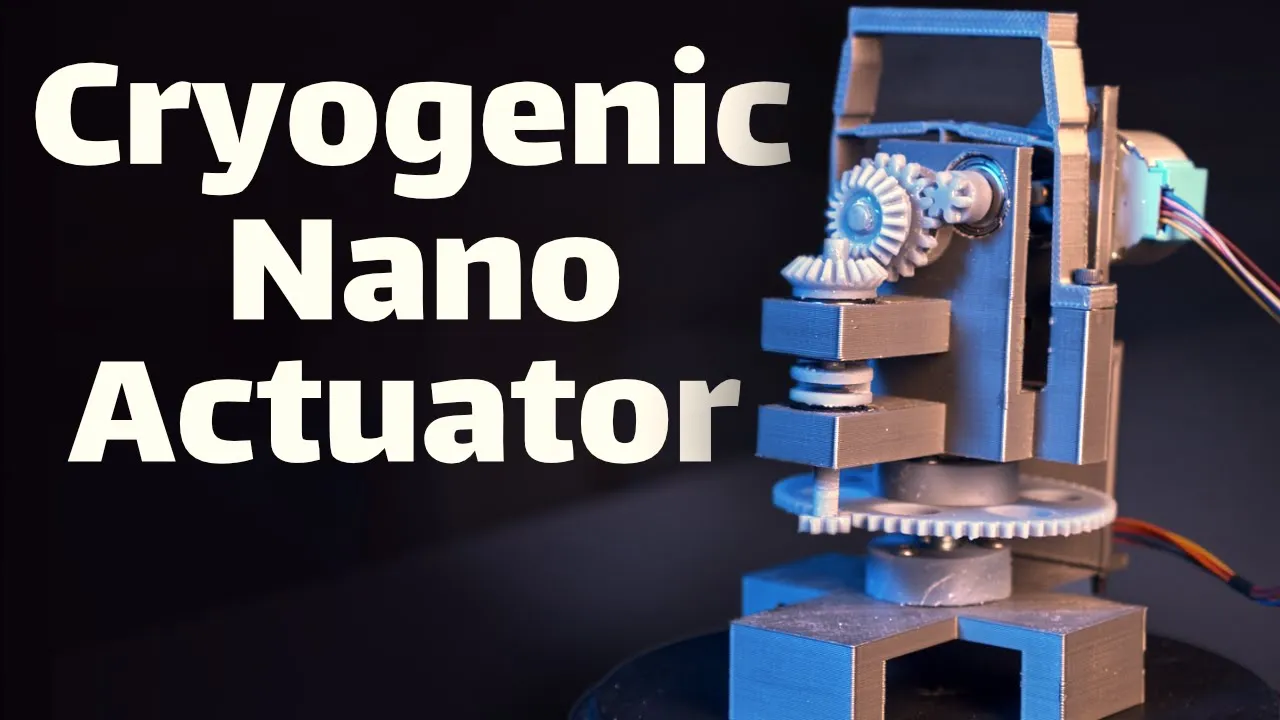
To demonstrate how such precision is physically achieved, the host reverse-engineered and 3D printed a true-to-scale functional replica. Using a 2006 technical paper published by Ball Aerospace that contained partial mechanical drawings and gear train details, he CAD-modeled the mechanism around off-the-shelf components. The actual flight units measure roughly 150 millimeters in length. While the 3D-printed replica is marginally larger due to the physical size of standard hobbyist bearings, it maintains the core architecture, reproducing the gear reductions and flexure geometries almost verbatim.
---
[04:04](https://www.youtube.com/watch?v=5MxH1sfJLBQ&t=244s) The Fine Positioning Stage and Flexure Mechanism
The core mechanical challenge is achieving 2-nanometer steps without relying on complex, active closed-loop servo feedback that generates heat. The actuator accomplishes this through pure mechanical advantage across a multi-stage gear and flexure reduction train powered by a single internal stepper motor.
```mermaid flowchart LR accTitle: Actuator Drive Train Architecture accDescr: Mechanical power flow from the stepper motor through gear reductions to the fine flexure and coarse ball screw stages.
subgraph Drive["Input & Primary Reduction"] M["Stepper Motor"] --> P["1:60 Planetary Gear"] P --> S["3:1 Spur Gears"] end
subgraph FineStage["Fine Stage"] S --> C["Offset Camshaft"] C -->|"displaces center ~1 mm"| F["Planar Flexure Joint"] F -->|"deflects top ~2 µm"| OUT1["Fine Output (2 nm / step)"] end
subgraph CoarseStage["Coarse Stage"] S --> B1["1:1 Bevel Gears"] B1 --> CP["Pin Coupler (~320° Backlash)"] CP --> G["1:8 Gear Reduction"] G --> BS["Lead / Ball Screw"] BS --> OUT2["Coarse Output (21 mm travel)"] end ```
The flight unit uses an internal stepper coupled to a 1:60 planetary gearhead (substituted in the replica with a common 28BYJ-48 stepper motor, which has an internal 1:64 reduction). The output turns a spur gear set providing a 3:1 reduction, which directly rotates an offset camshaft.
This camshaft drives the center section of a monolithic planar flexure. As the offset cam rotates, it displaces the center section of the flexure upward by a macroscopic amount (around 1 mm in simulation). This central displacement pulls the lateral flexure arms inward, transferring an attenuated motion to the very top mounting interface:
- The flexure behaves as a mechanical motion divider: a 1 mm vertical displacement at the center results in only a few microns of travel at the top. - The flexure geometry offers vast design latitude: engineers can fine-tune arm spacing, material stiffness, joint cross-sections, and arm angles to achieve the exact displacement ratio desired. - Compounding the stepper angle, the planetary gearhead (1:60), the spur gear set (3:1), and the flexure attenuation produces an astonishing 2 nanometers of linear displacement per motor step.
As the host notes regarding the elegant simplicity of the system: “An interesting thing about this mechanism is it gives you a ton of precision essentially for free because you've got the resolution of the stepper itself you've got the gear reduction of the planetary gear you've got the gear reduction of the spur drive and then you've got the reduction of the flexure itself.” While sensor suites exist on the telescope to measure position, the mechanism itself achieves its fidelity open-loop purely through geometry and mechanics.
---
[06:47](https://www.youtube.com/watch?v=5MxH1sfJLBQ&t=407s) Coarse Positioning Stage and Lost-Motion Pin Coupling
Rather than adding the weight and thermal penalty of a second motor, Ball Aerospace engineered a way to drive both the fine stage and the 21 mm coarse stage using the exact same stepper motor. The primary spur gear meshes with a 1:1 bevel gear set, routing drive torque down a central shaft to a specialized coupling disc.
This coupling mechanism exploits an intentional "lost motion" design using protruding pins on mating disc faces, creating roughly 320° to 330° of rotational backlash:
1. **Fine Control Window:** Within that ~320° window of rotation, the drive pin moves freely through open space without contacting the coarse stage pin. In this zone, only the camshaft and flexure operate, giving precise control over the 10 µm fine adjustment range. 2. **Coarse Engagement:** When the motor continues rotating in one direction past the deadband, the drive pin strikes the mating pin, physically locking the coarse stage drive. Continuous rotation in that direction drives a secondary 1:8 gear reduction connected directly to a precision ball screw, translating the entire mechanism along its 21 mm coarse path. 3. **Disengagement & Direction Reversal:** To return to fine positioning, the motor simply reverses direction. The pins immediately separate, freeing the system to make fine sub-micron adjustments within the new coarse position. If coarse adjustment in the opposite direction is needed, the motor reverses through the full 320° deadband until the pins make contact on their opposing faces.
---
[08:37](https://www.youtube.com/watch?v=5MxH1sfJLBQ&t=517s) Torsional Stabilizer, Hexapod Kinematics, and DIY Notes
Because the actuator rides atop a rotating ball screw with its drive motor mounted on top of the moving assembly, running the screw would naturally cause the actuator body to spin freely in place instead of translating vertically. To prevent this, Ball Aerospace integrated a torsional stabilizer along the spine of the unit. This stabilizer is an external flexure linkage that permits free linear extension along the primary axis of travel while remaining extremely stiff against torsional rotation.
Six of these linear actuators are connected to each of the 18 primary mirror segments to form a Stewart platform (hexapod). By coordinating the relative extension and retraction of all six actuators simultaneously, the system achieves complete kinematic control across all six spatial degrees of freedom.
For makers looking to replicate the project using the files posted to platforms like Thingiverse and Printables, the host offers practical advice: - The CAD files are faithful to the flight design and are not optimized for loose 3D-printer tolerances; extensive filing, sanding, and gluing are required to get parts fitting smoothly. - A standard M8 screw was substituted in place of the custom 21 mm space-flight ball screw. Because standard hardware introduces play, makers should anticipate loose fits, wrap threads in Teflon tape, or source fine-pitch threaded rods to reduce slop. - Credit for bringing the technical details of the actuator to light goes to *The Orbital Mechanics Podcast*, whose JWST coverage inspired the build.
[10:33](https://www.youtube.com/watch?v=5MxH1sfJLBQ&t=633s) Podcast Recommendation and Wrap-Up
Wrapping up the discussion on the James Webb Space Telescope's mirror actuators, the host gives an enthusiastic plug for *The Orbital Mechanics* podcast, recommending it to anyone interested in the space industry. He mentions having followed the show for quite some time, noting, “I've been listening for a couple years now and it's great, I love it, so check that out if that sounds interesting to you.” A link to the podcast is provided in the video description for curious viewers who want deeper dives into aerospace engineering and spaceflight news.
Turning to the standard YouTube sign-off, the host steers the audience toward the algorithmically suggested content on screen, inviting them to check out whichever video Google thinks they might like next. Rather than running through a rote checklist of calls to action, he wryly urges viewers to “do the things people tell you to do at the ends of videos,” before offering a final thanks and signing off until the next project.
## Mentioned Ball Aerospace, Breaking Taps, Destin Sandlin, Google, James Webb Space Telescope, NASA Goddard Space Flight Center, Printables, Smarter Every Day, Stewart platform, The Orbital Mechanics Podcast, Thingiverse
## Video description The cryogenic mirror actuators on JWST are amazing feats of engineering. Capable of long travel and nanometer precision, able to survive rocket launch, cryogenic temperatures and hard vacuum... they are really impressive devices. And they use flexures!
CONSIDER SUBSCRIBING 🥰 ☕Buy me a coffee? https://www.buymeacoffee.com/Breakingtaps 🔬Or Patreon if that's your jam: https://www.patreon.com/breakingtaps 📢Twitter: https://twitter.com/BreakingTaps 💻Discord: https://discord.gg/R45uCXcEv4
==== Links ==== - "Cryogenic Nano-Actuator for JWST": https://www.esmats.eu/amspapers/pastpapers/pdfs/2006/warden.pdf - Orbital Mechanics Podcast: https://theorbitalmechanics.com/ - NASA Goddard Spaceflight Center's video on mirror alignment: https://www.youtube.com/watch?v=2dh41uouutU - Ball & Ball Aerospace history, because lol what? 😂 https://www.ball.com/our-company/our-story/history-timeline
- Thingiverse: https://www.thingiverse.com/thing:5232214 - PrusaPrinters: https://www.prusaprinters.org/prints/129373-jwst-mirror-actuators
- Shirt is from Destin over at Smarter Every Day: https://www.bonfire.com/store/smarter-every-day/
==== Timeline ==== 0:00 Mirror actuator 2:11 Actuator specs 3:06 3D printed replica 4:04 Fine positioning stage 6:47 Coarse positioning stage 8:37 Torsional stabilizer 9:08 Hexapod arrangement 9:38 Assembling and printing notes
[Source](https://www.youtube.com/watch?v=5MxH1sfJLBQ)